
Hardware / Research systems
Products
Build your system from visual-inertial capture, tactile sensing and robot learning hardware. Compare specifications, configuration options and development status.
Ego Thor
Compare the series →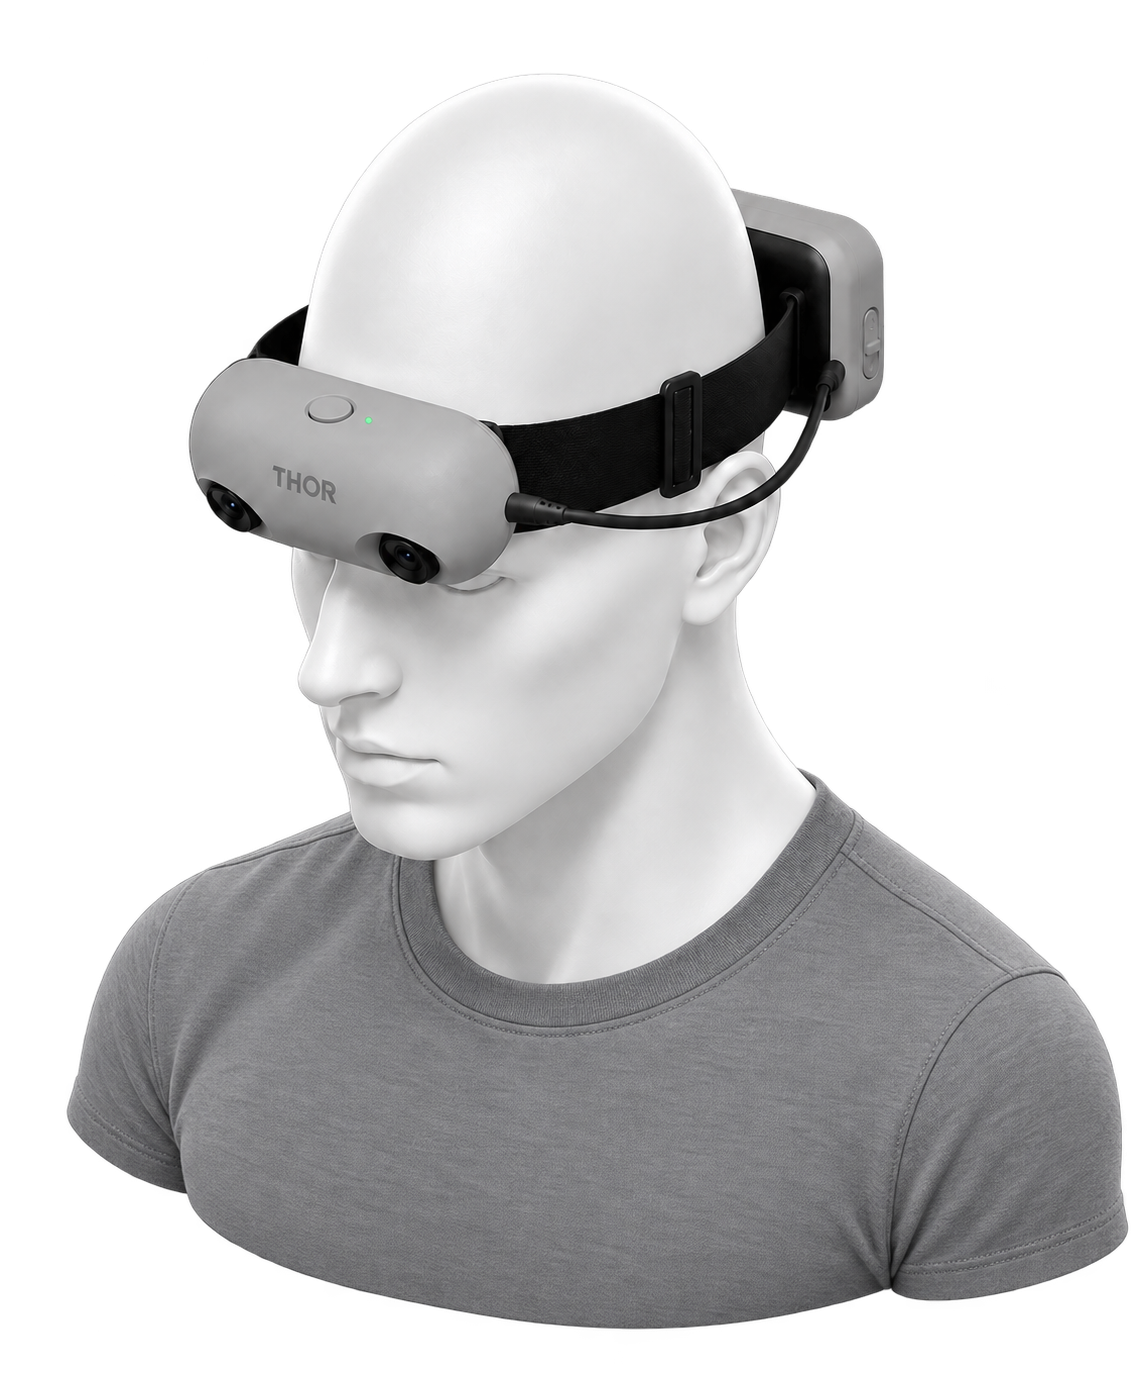
Capture / Specification-based configuration
Thor-Duo
Dual-camera visual-inertial capture
- 30 FPS per camera
- 2 x 1080P
- IMU sampling
- 300 Hz
- Nominal system weight
- Approx. 180 g
Capture / Specification-based configuration
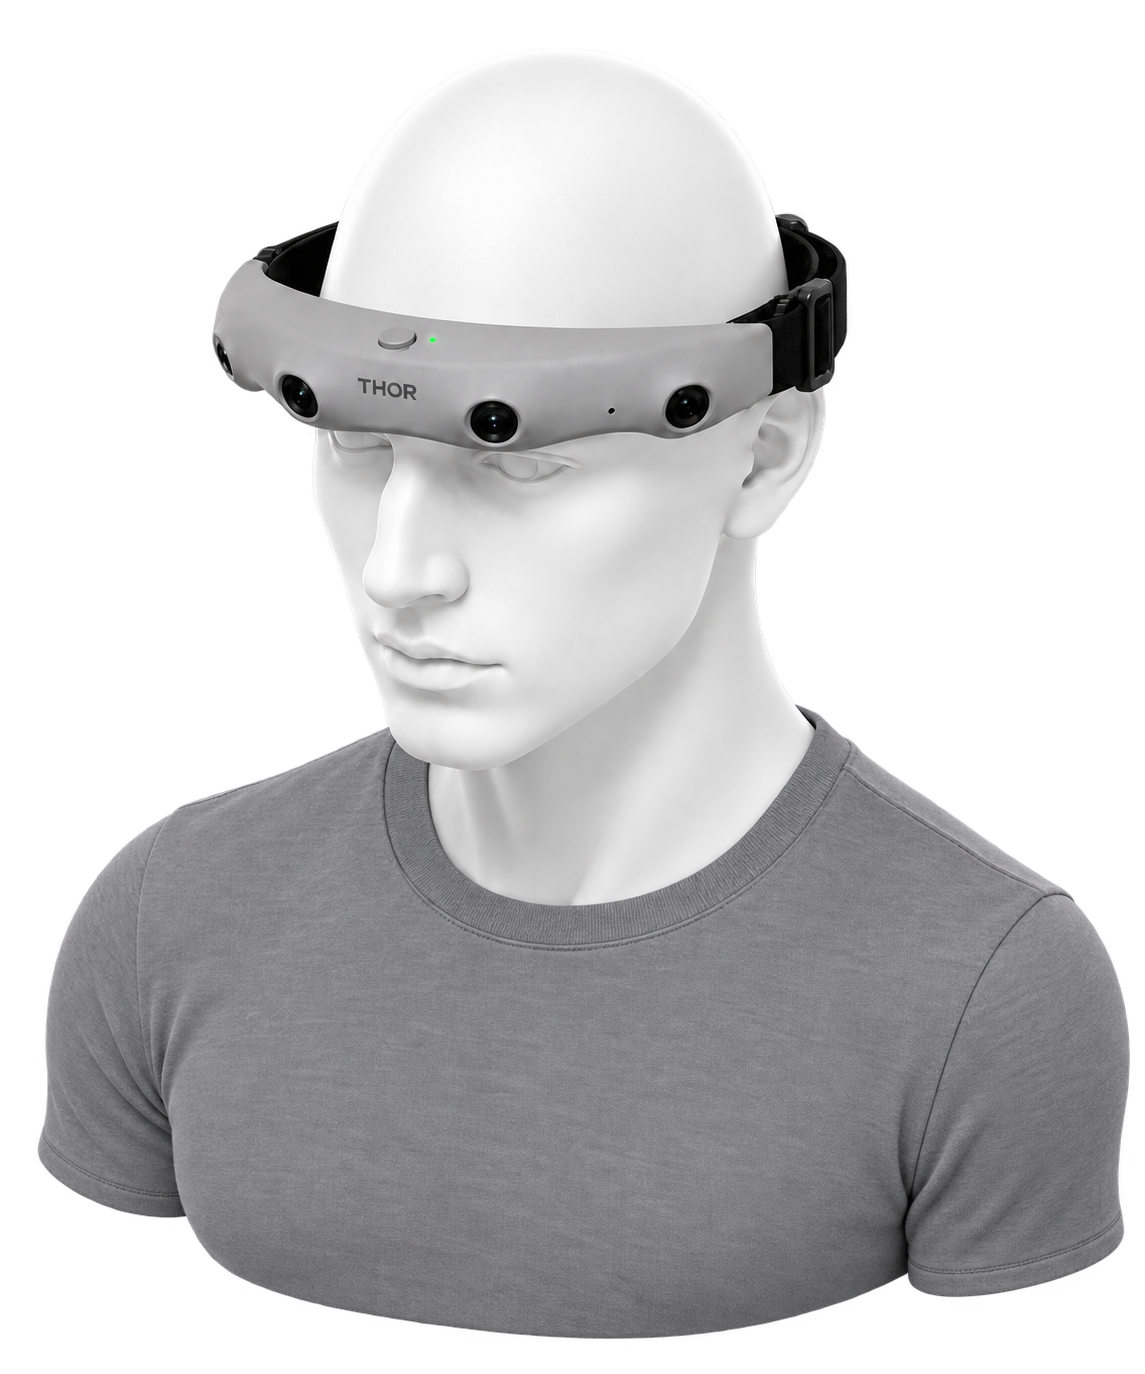
Thor-Quad
Four-camera visual-inertial capture
- 30 FPS per camera
- 4 x 1080P
- IMU sampling
- 300 Hz
- Nominal system weight
- Approx. 500 g
Capture / Specification-based configuration
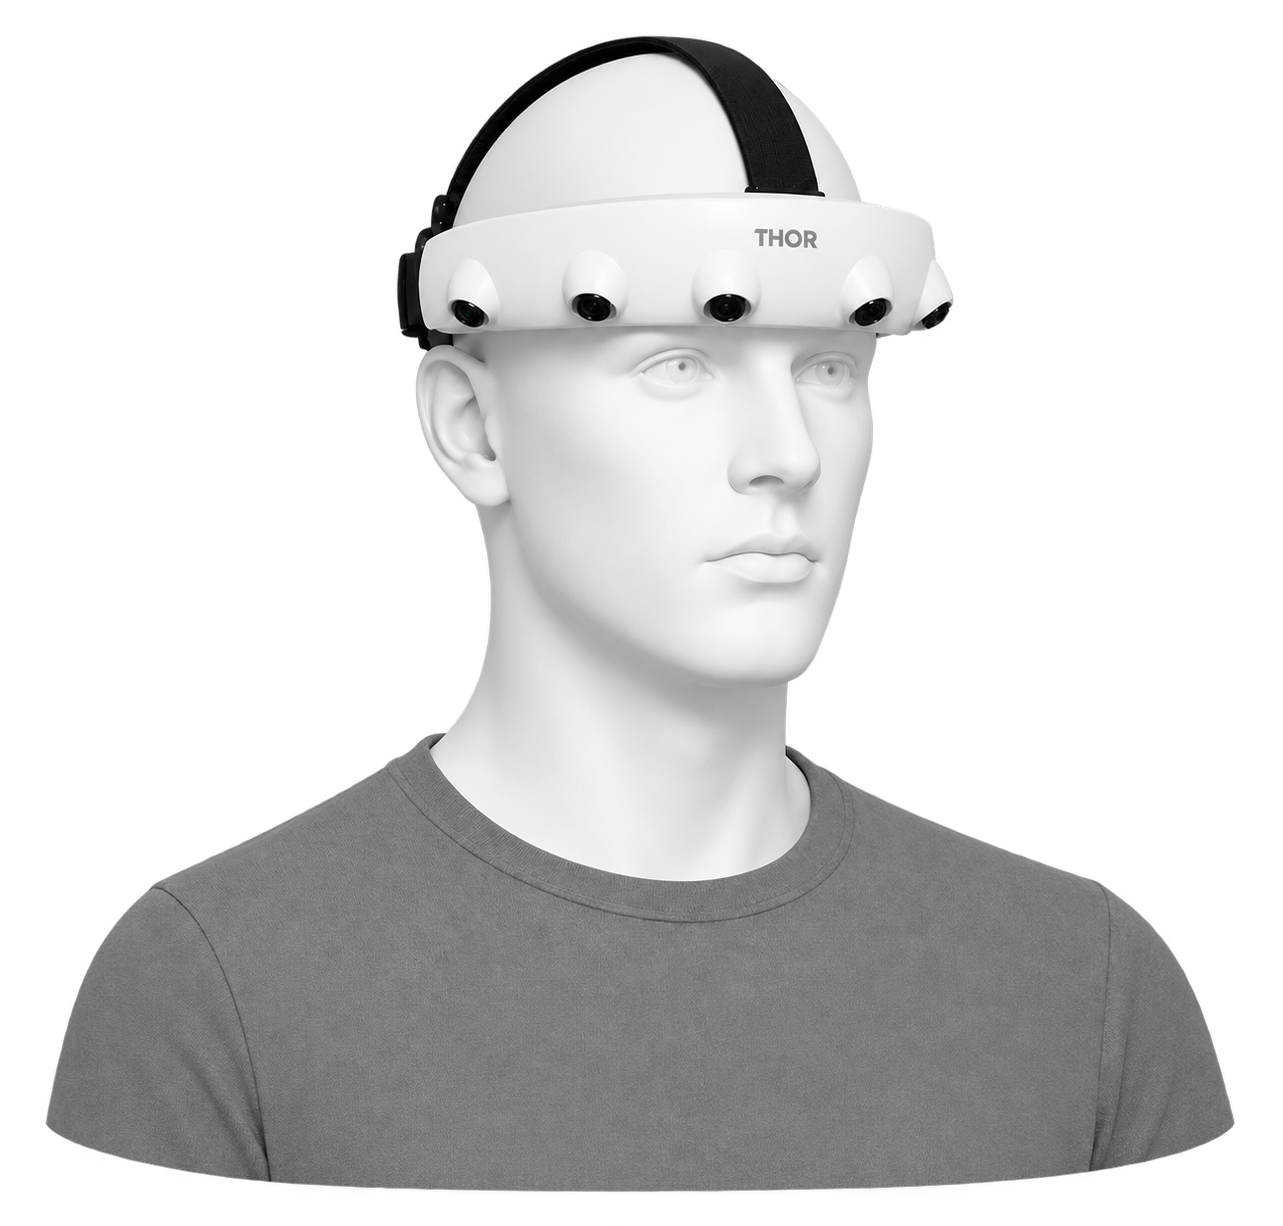
Thor-Hex
Six-camera visual-inertial capture
- 30 FPS per camera
- 6 x 1080P
- IMU sampling
- 300 Hz
- Nominal system weight
- Approx. 650 g
Multimodal Capture
Capture / Specification-based configuration
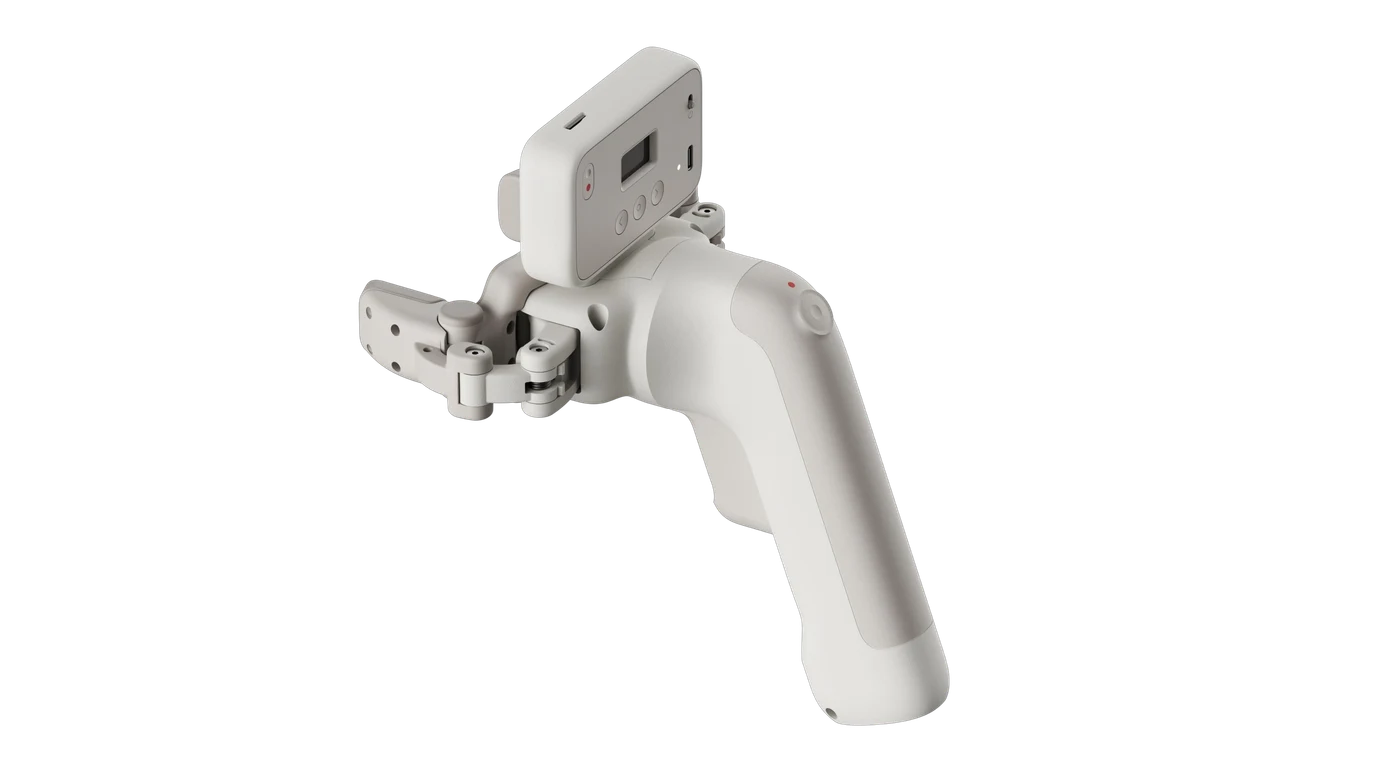
UMI Gripper
Handheld manipulation demonstrations
- Global-shutter video
- 60 FPS
- IMU sampling
- 500 Hz
- Width and GT tactile output
- 100 Hz
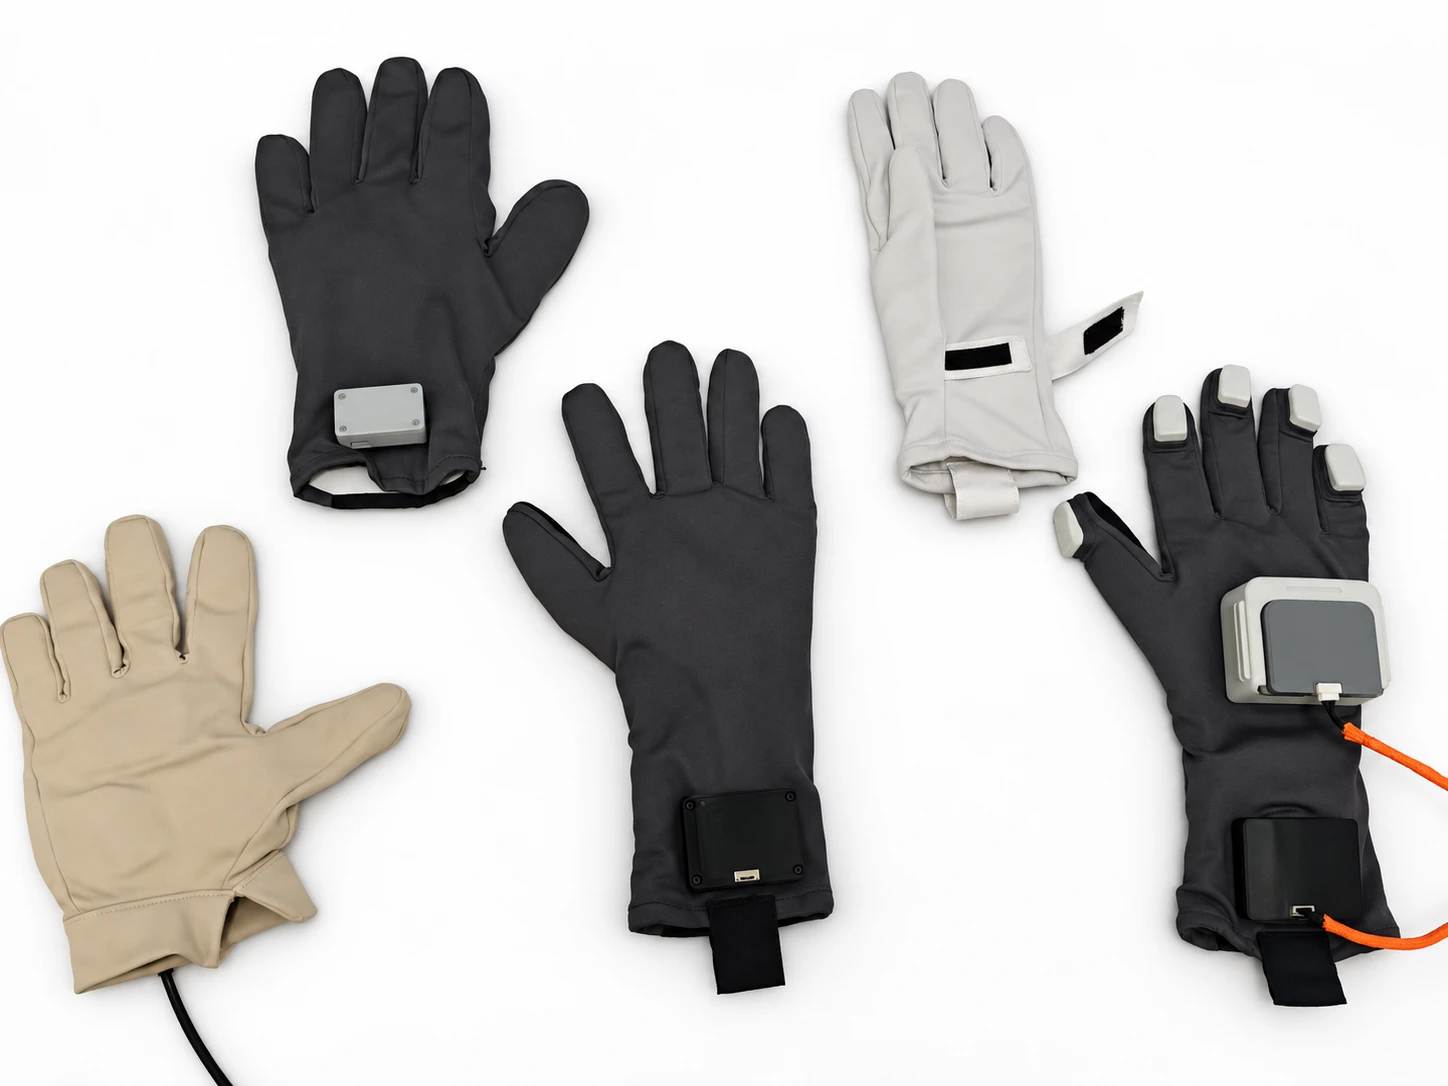
Capture / Specification-based configuration
Tactile Data Glove
Contact sensing and electromagnetic tracking
- Standard tactile layout
- 360 points
- Nominal tactile sampling
- 200 Hz
- Nominal tracking output
- 180 Hz
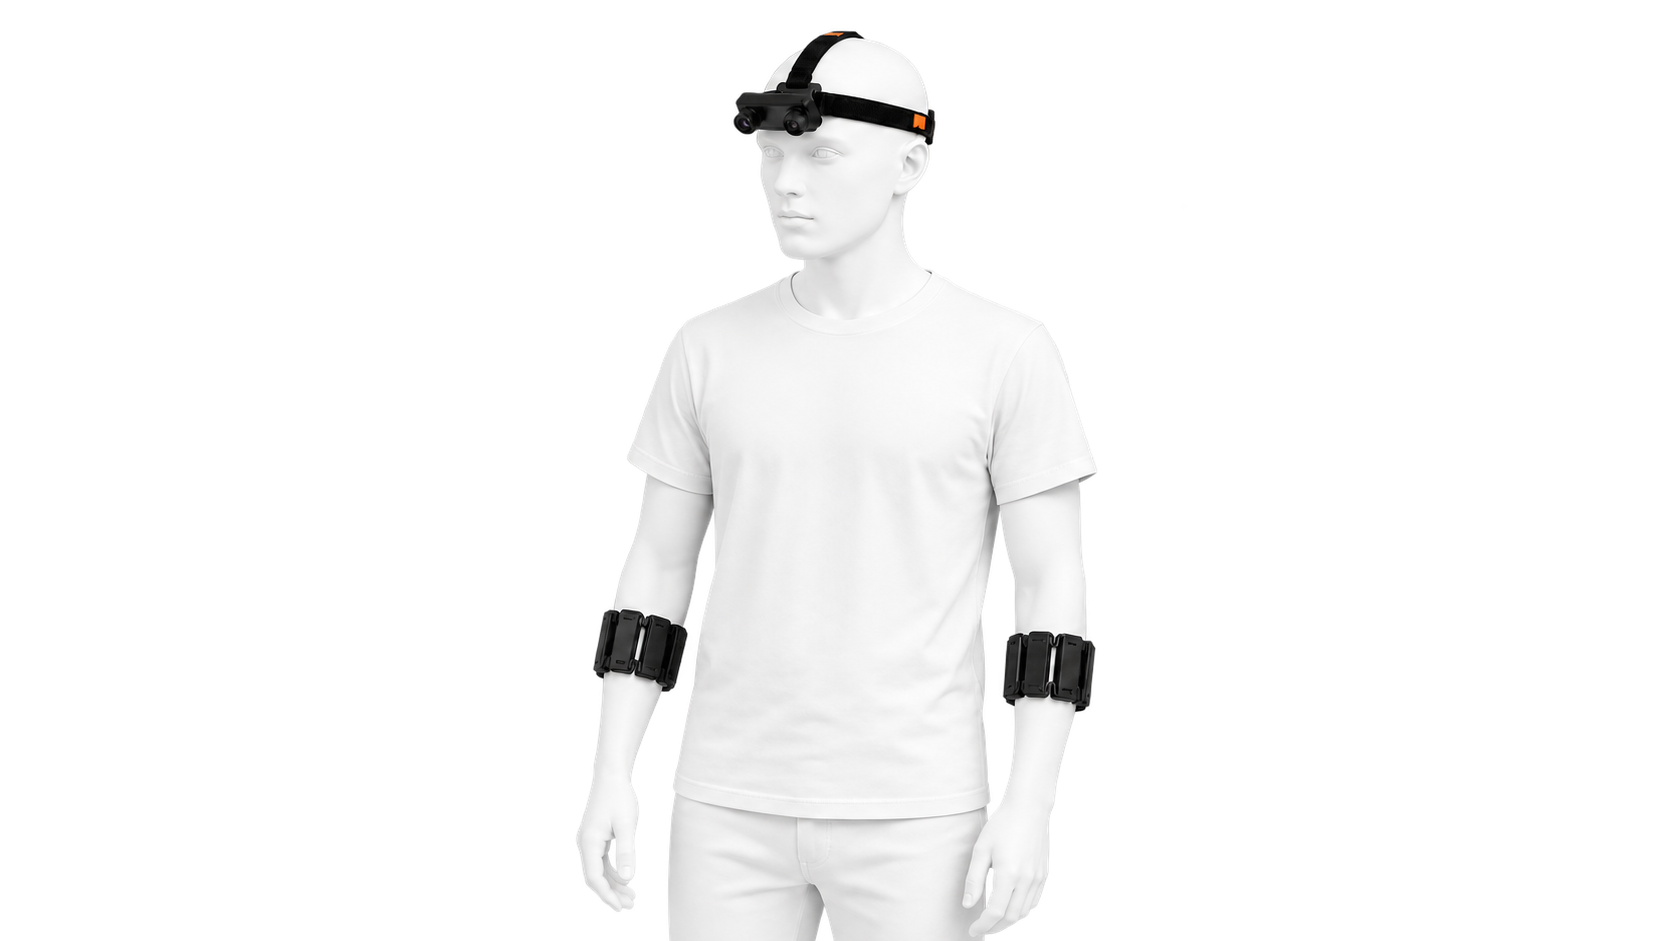
Capture / Research validation
FMG + IMU
Forearm sensing for multimodal research
- Pressure patterns and motion
- FMG + IMU
- Left and right forearm capture
- Bilateral
- First-person task context
- Ego pairing
Atlas Robotics
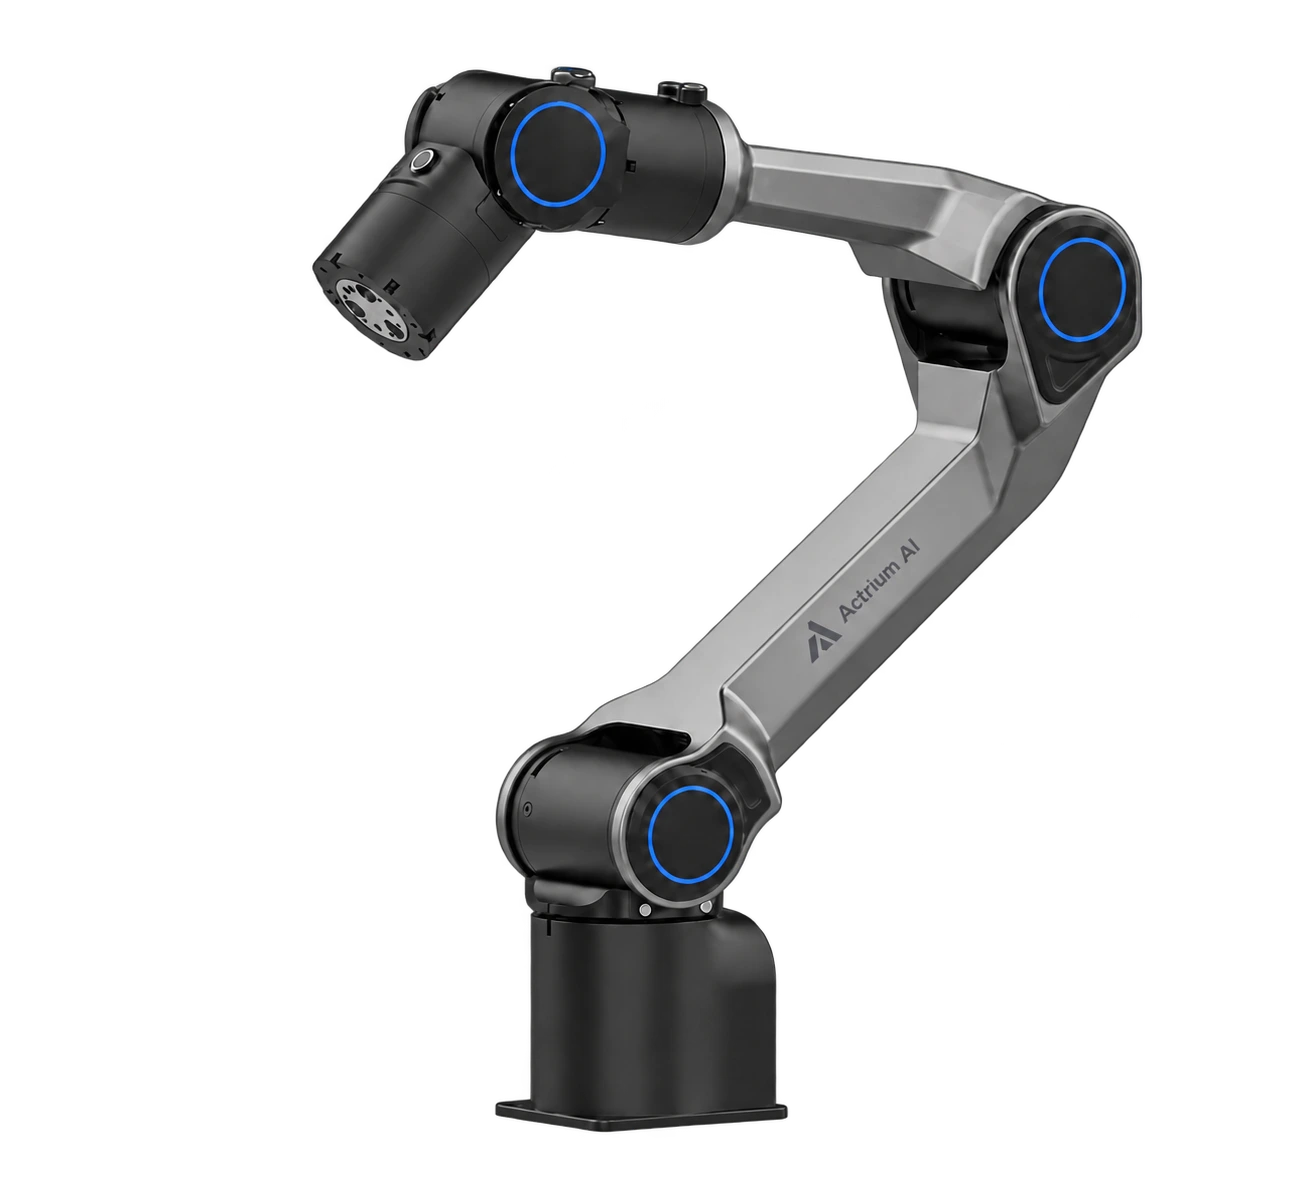
Robotics / Project configuration
Atlas A6
Six-axis research manipulator
- Degrees of freedom
- 6
- Arm mass
- 4.2 kg
- Repeatability
- +/-0.1 mm
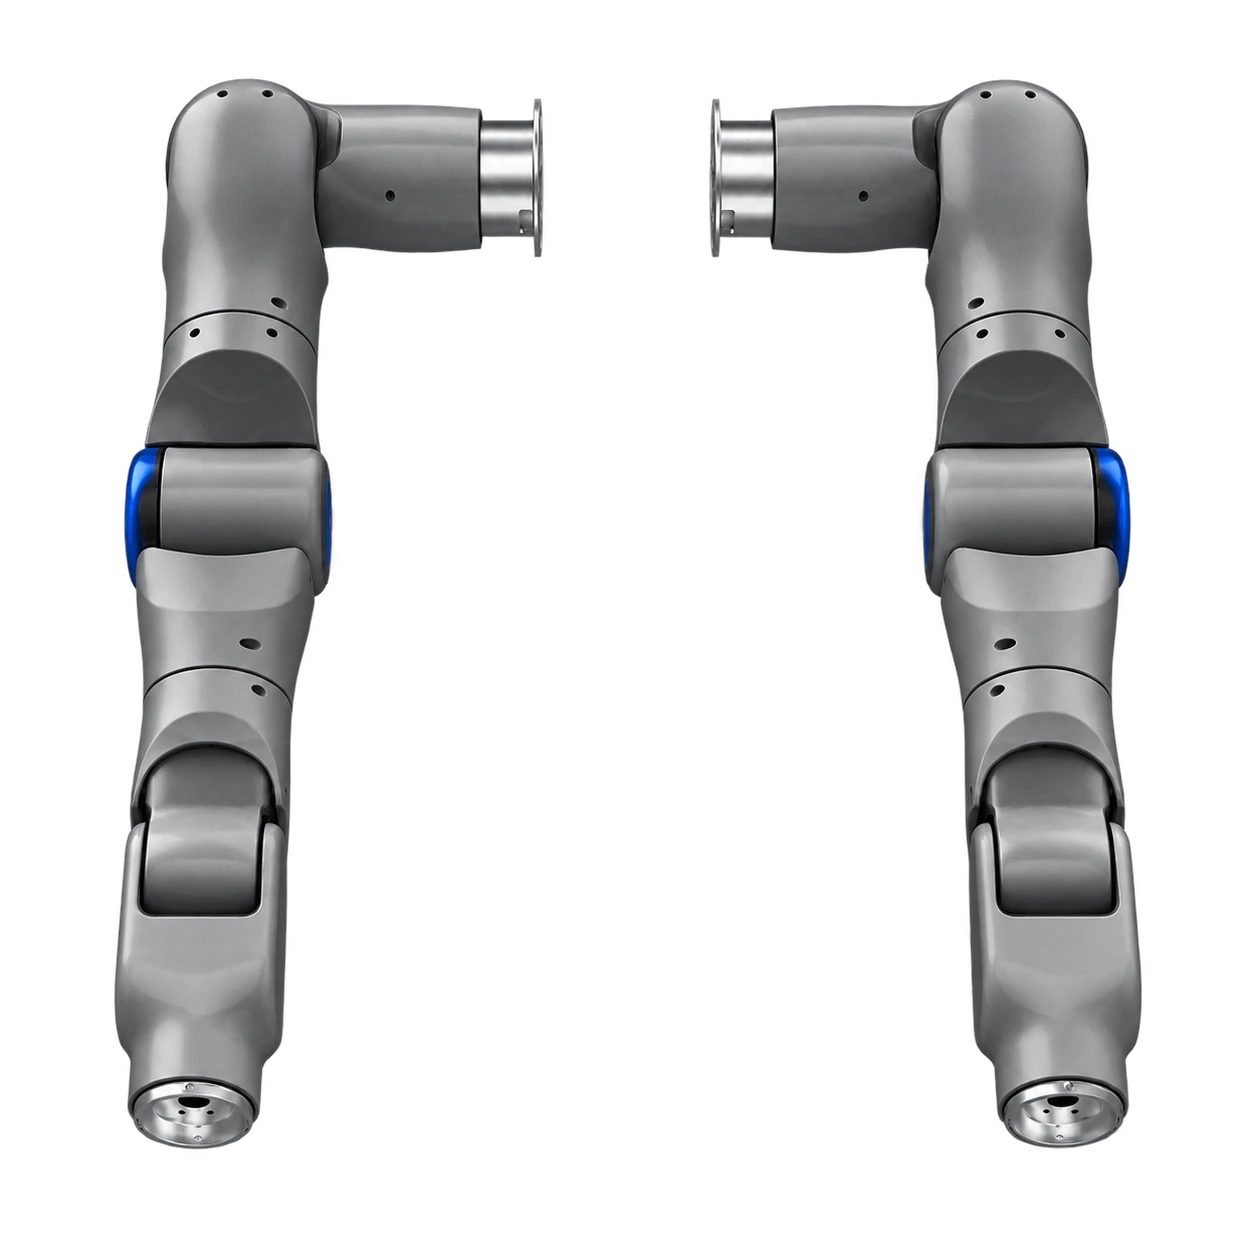
Robotics / Project configuration
Atlas A7
Seven-axis lightweight research manipulator
- Redundant kinematics
- 7 axes
- Nominal maximum payload
- 3 kg
- Nominal maximum reach
- 739.45 mm
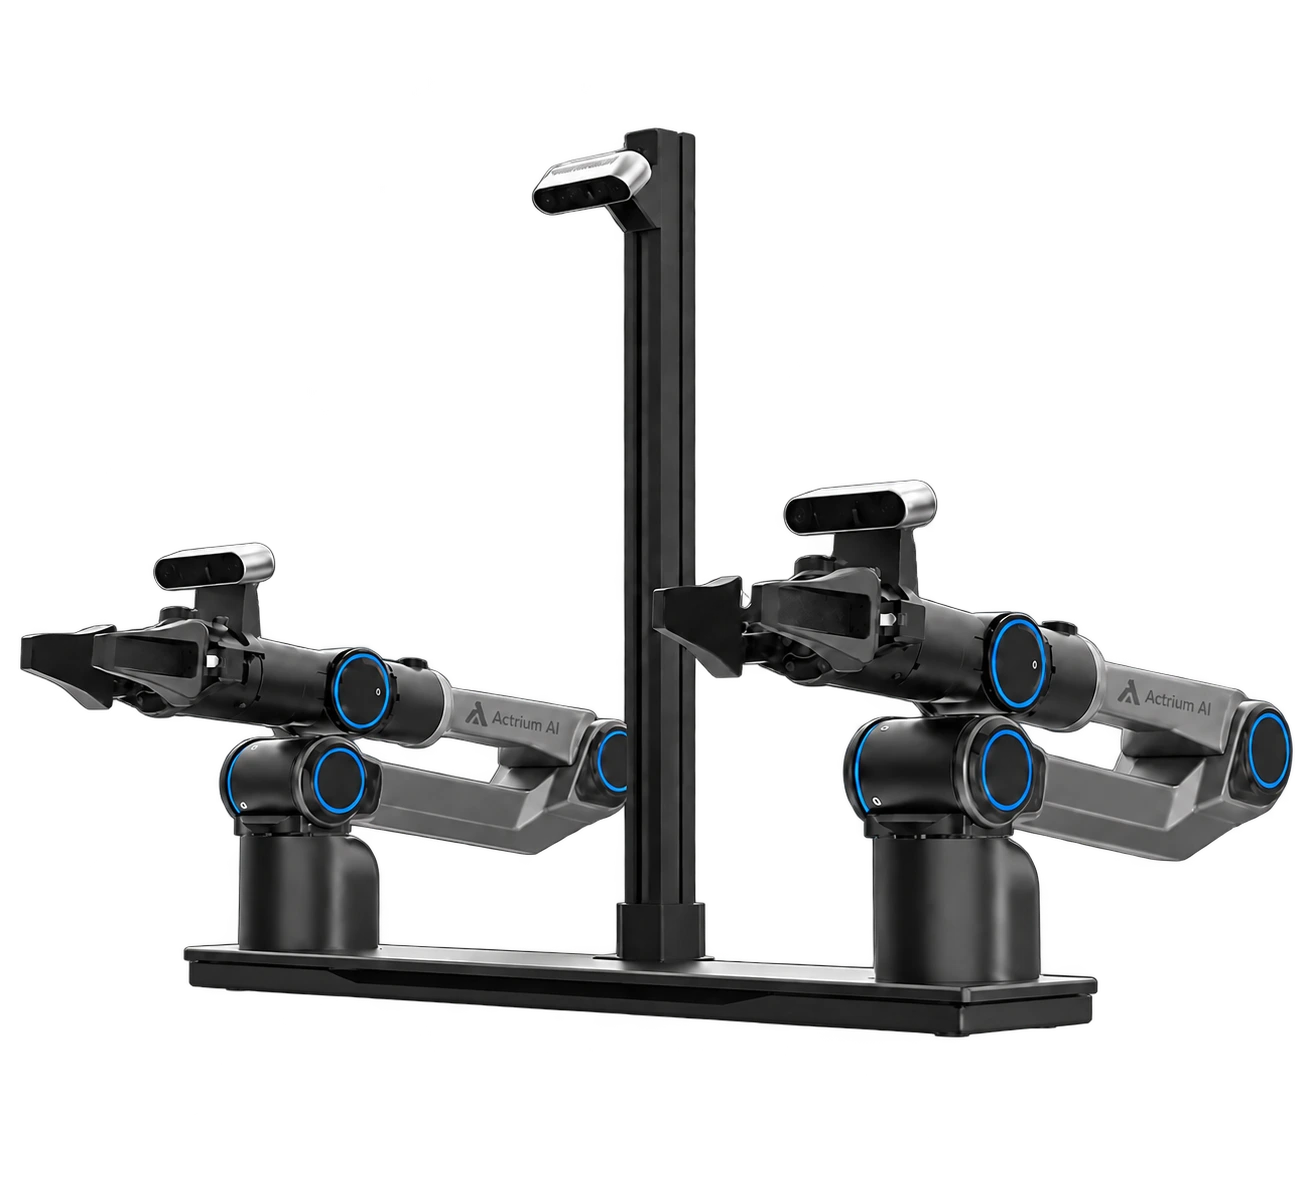
Robotics / Project configuration
Atlas D
Desktop bimanual learning platform
- Leader-follower setup
- 4 arms
- Reference single-arm payload
- 1.5 kg
- Reference single-arm reach
- 626 mm
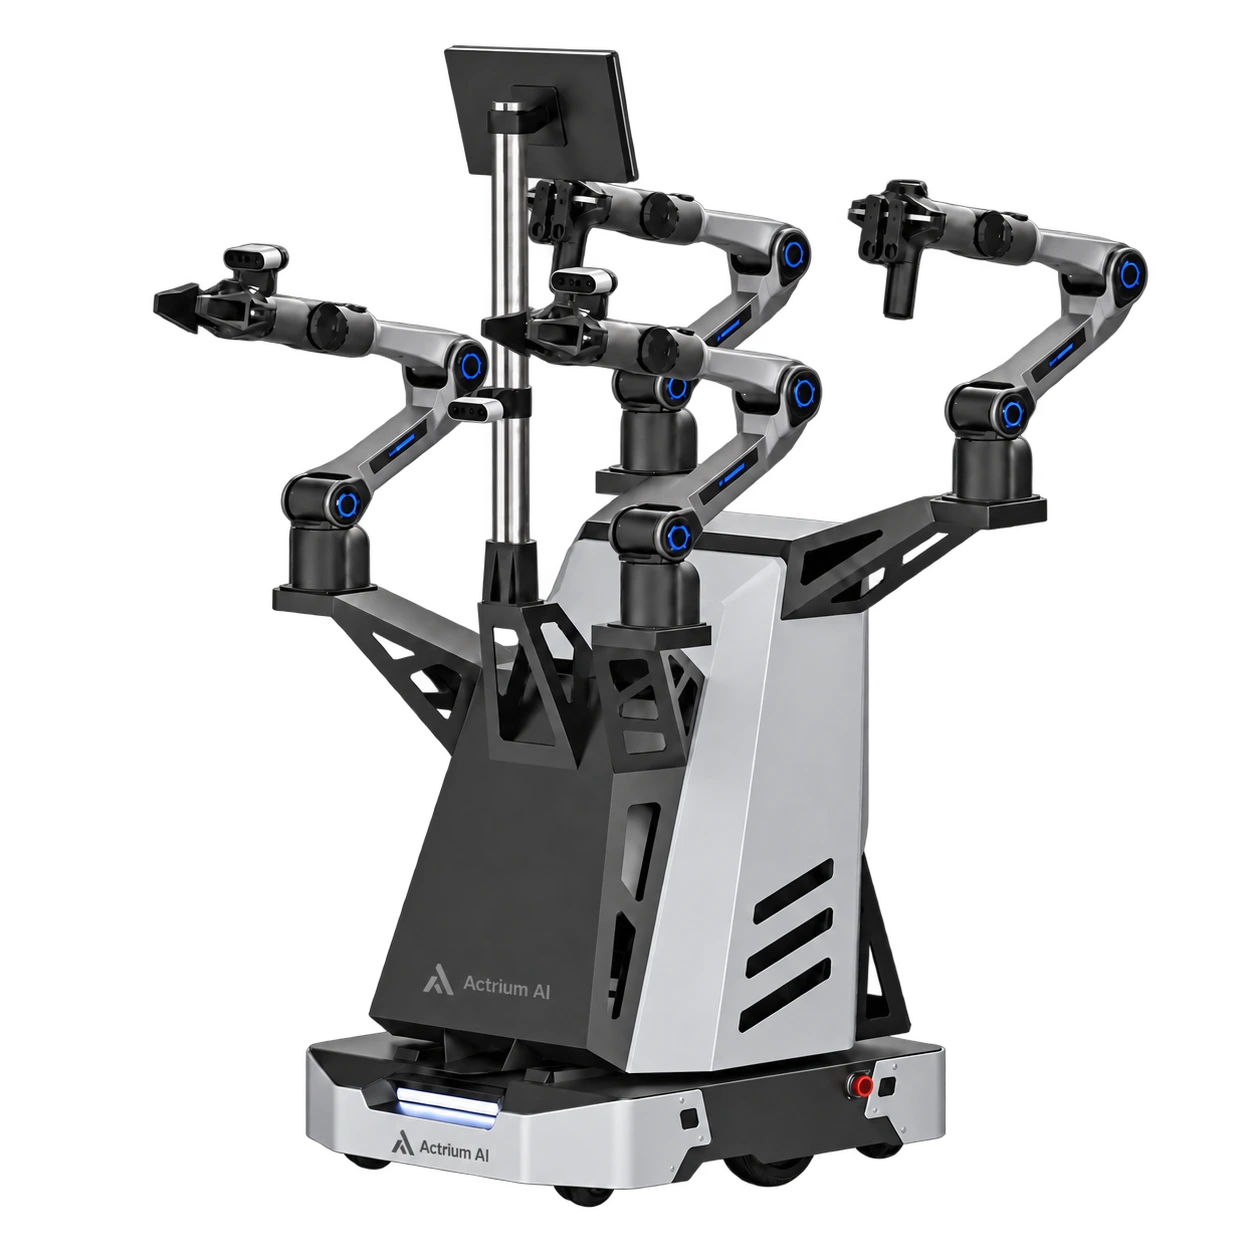
Robotics / Project configuration
Atlas M
Integrated mobile bimanual platform
- Leader-follower teleoperation
- Dual arm
- Reference manipulators
- 6 axes
- GPU configuration options
- 4070-5090
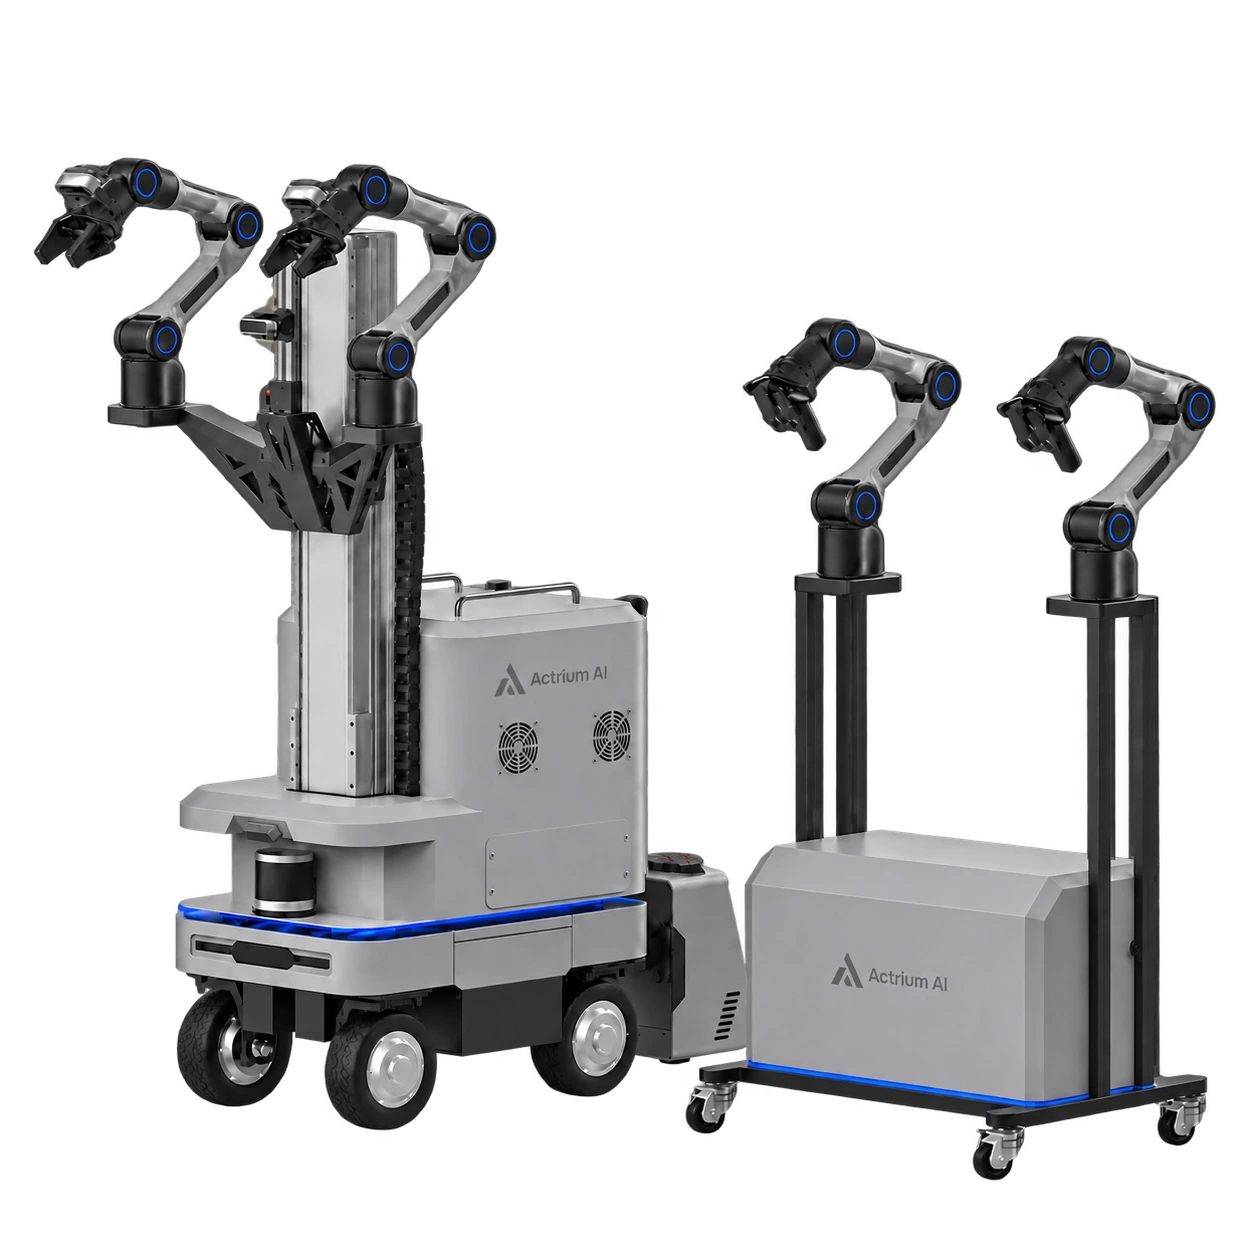
Robotics / Project configuration
Atlas S
Modular mobile bimanual platform
- Leader-follower setup
- 4 arms
- Maximum base speed
- 2 m/s
- Base protection rating
- IP54
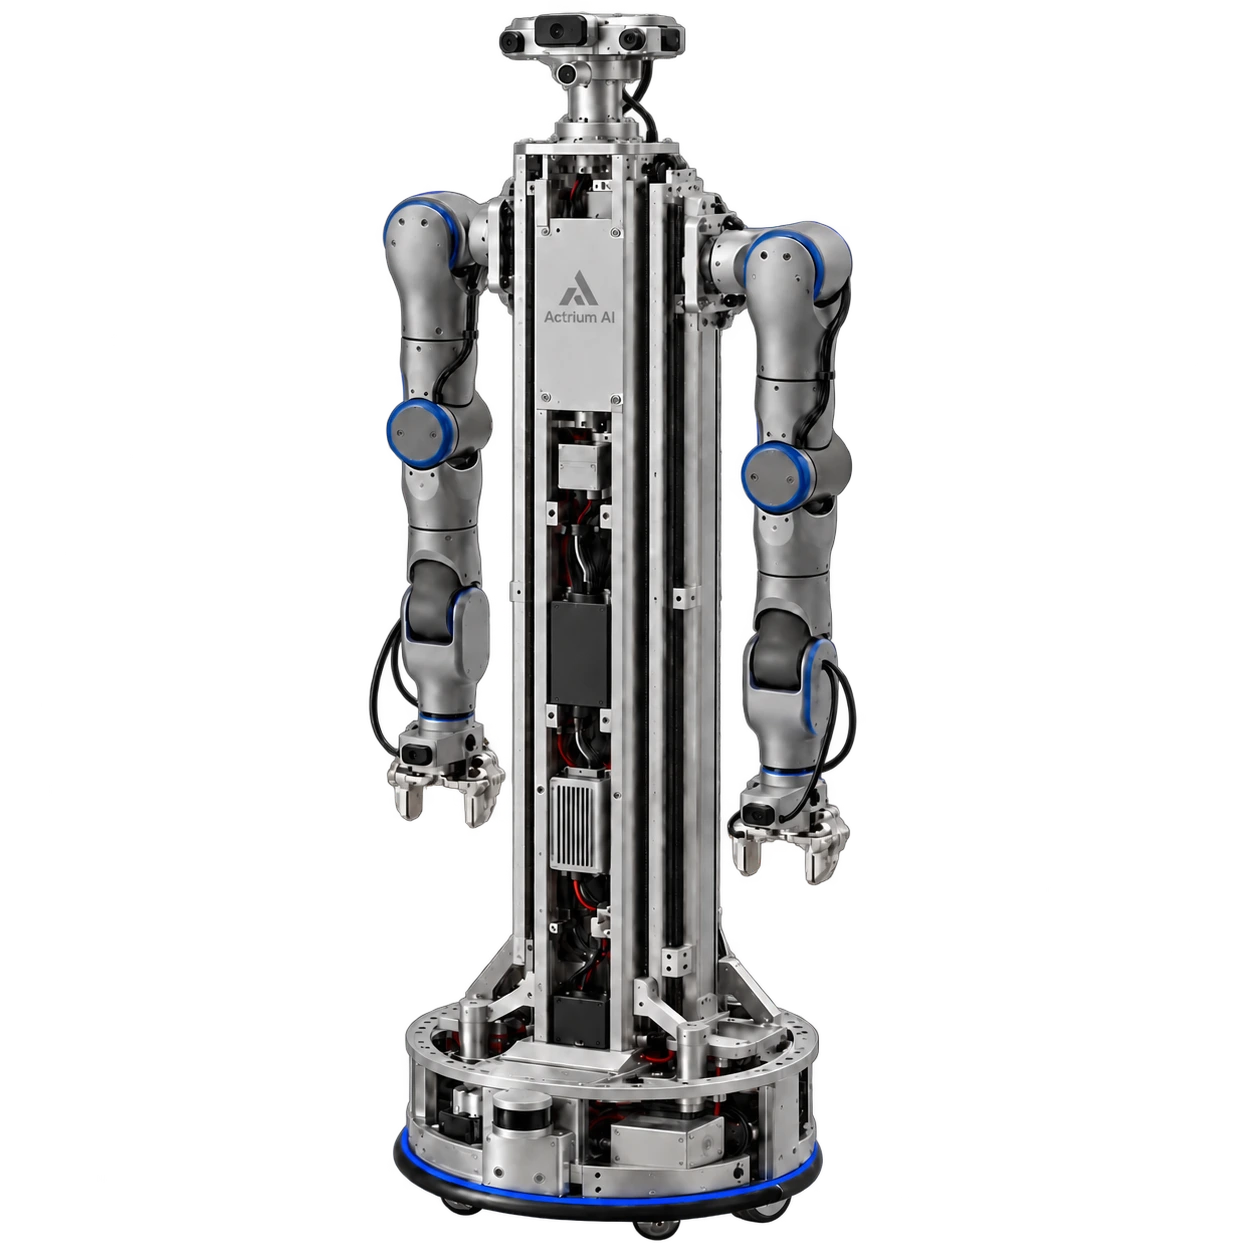
Robotics / Research concept
Atlas R1
Open-frame wheeled humanoid research concept
- Mobile manipulation
- Wheeled
- Bimanual research
- Dual arm
- Concept architecture
- Open frame
Build with Actrium
Start with your task.
Define the devices, data and evaluation your project needs.