Hands remain free
Forearm bands support natural contact without covering the palms or fingertips. They do not replace every tactile or hand-pose sensor.

Capture
Research validation
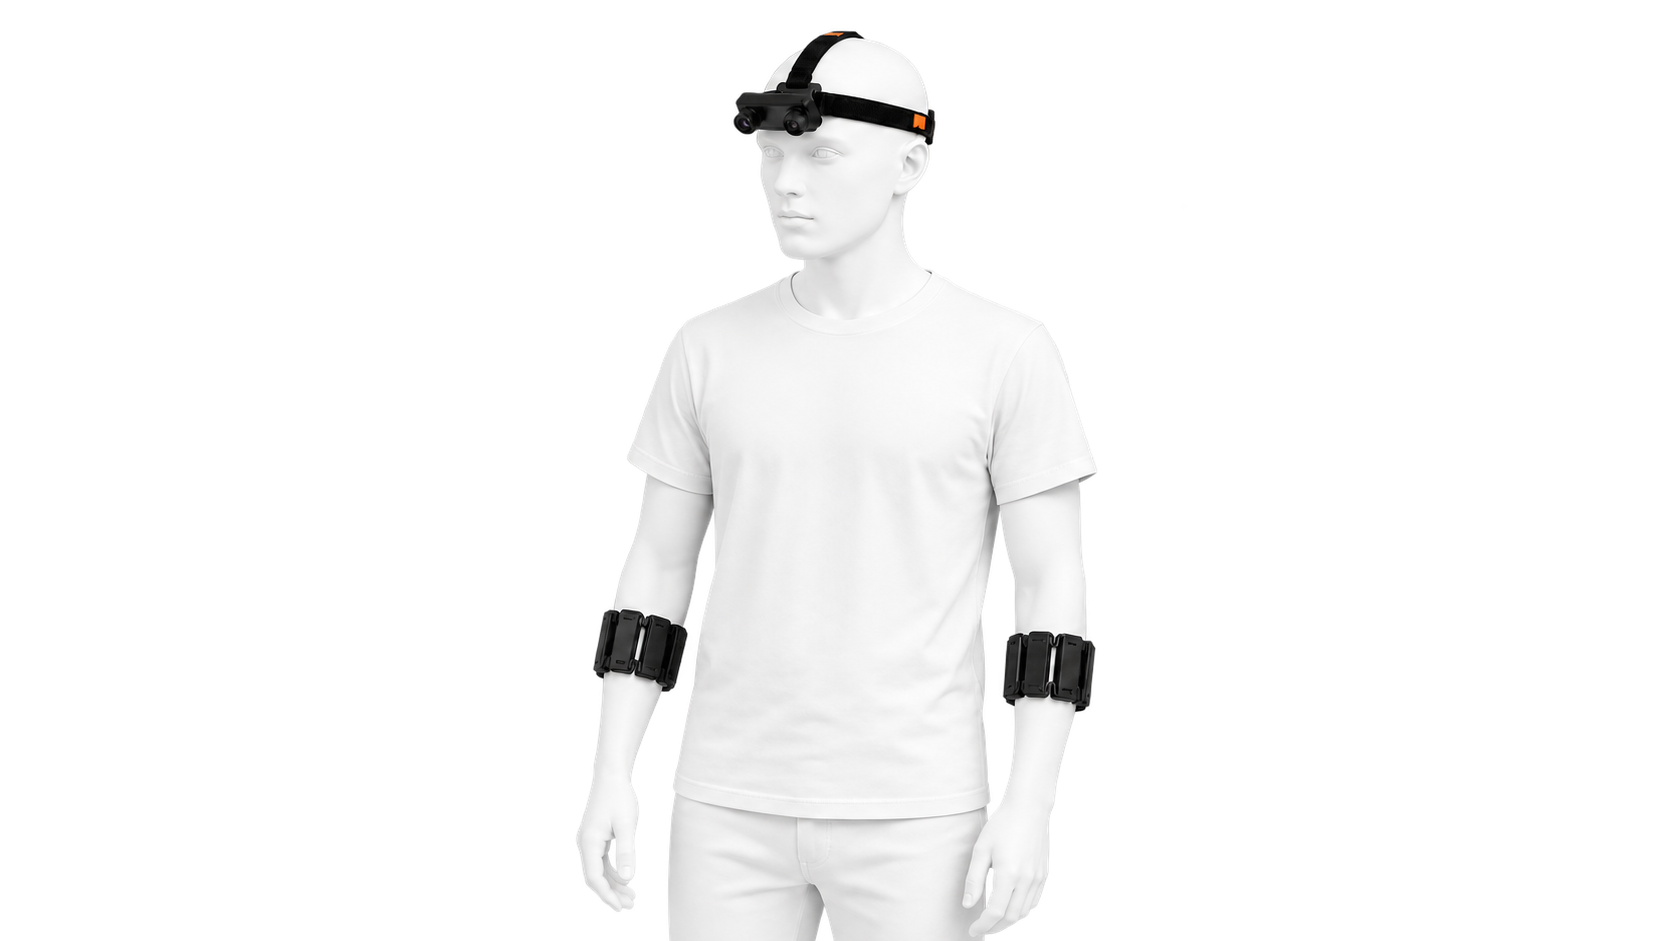
System overview
Pair forearm pressure patterns associated with muscle deformation and inertial motion with first-person video. A head-mounted camera and two forearm bands keep the palms and fingertips free for natural interaction.
Configuration, lead time and delivery scope confirmed with your inquiry.
Explore in 3DFMG + IMU / In three dimensions
Loading 3D preview...
Conceptual exterior and layout only, not engineering CAD. Internal structures, materials and dimensions require project-specific confirmation.
Design & capability
Forearm bands support natural contact without covering the palms or fingertips. They do not replace every tactile or hand-pose sensor.
A modular band combines inward-facing contact elements and an IMU. Forearm pressure changes are not measurements of fingertip-object force.
Gesture, 3D hand-pose and fingertip-pressure prediction are research directions requiring independent labels, cross-user testing and robot task comparisons.
Configuration details and measurement conditions.
| Signals | FMG + IMU; no EMG channels |
|---|---|
| Form | Modular forearm band with inward-facing contact elements |
| Array | Demonstration material labels a 10 x 4 three-dimensional force-sensing array; measurement points, axes and independent channel count require confirmation |
| Frequency | 120 Hz is stated in demonstration material; sampling, transmission refresh and algorithm output rates must be defined separately |
| IMU | Axes, range, noise and sampling rate to be confirmed |
| Wearable setup | Head-mounted stereo vision + bilateral forearm bands; single / paired package scope to be confirmed |
| Communication | Wireless protocol, bandwidth, range and SDK to be confirmed |
Do not infer 40 or 120 data channels from the 10 x 4 label or the rendered module count.
| Raw records | FMG outputs, inertial signals, timestamps, sequence numbers and quality flags; final schema requires interface confirmation |
|---|---|
| Derived outputs | Model estimates of gestures, hand pose or fingertip pressure; dimensions, rate and accuracy require validation |
| Reference measurements | Independent hand-pose, force or tactile sensors and annotations selected for the task |
| Cross-device alignment | Clock mapping and synchronization events with Ego, UMI or robots; verify the error separately |
| Wear metadata | Anonymous participant ID, hand, position, orientation, fit, resting baseline, date and re-wearing events |
| Export | Session / episode organization with raw data, calibration and derived outputs; protocol and SDK licenses to be confirmed |
| Sensing | Range, accuracy, sensitivity, drift, hysteresis, overload and temperature effects |
|---|---|
| Fit | Forearm circumference, module adjustment, preload, long-session comfort and skin-contact materials |
| Power / structure | Weight, battery, runtime, charging, protection and cleaning |
| Link | End-to-end latency, packet loss, coexistence, reconnect and device concurrency |
| Software | Operating systems, raw-data access, SDK, model licenses and user calibration |
| Acceptance | Independent users, cross-day re-wearing and matched task baselines |
Delivery and validation
Research validation stage. Wearing concepts and demonstration videos are not test reports. FMG is not EMG or direct fingertip force ground truth. No unverified production, delivery or robot-performance claims are implied.
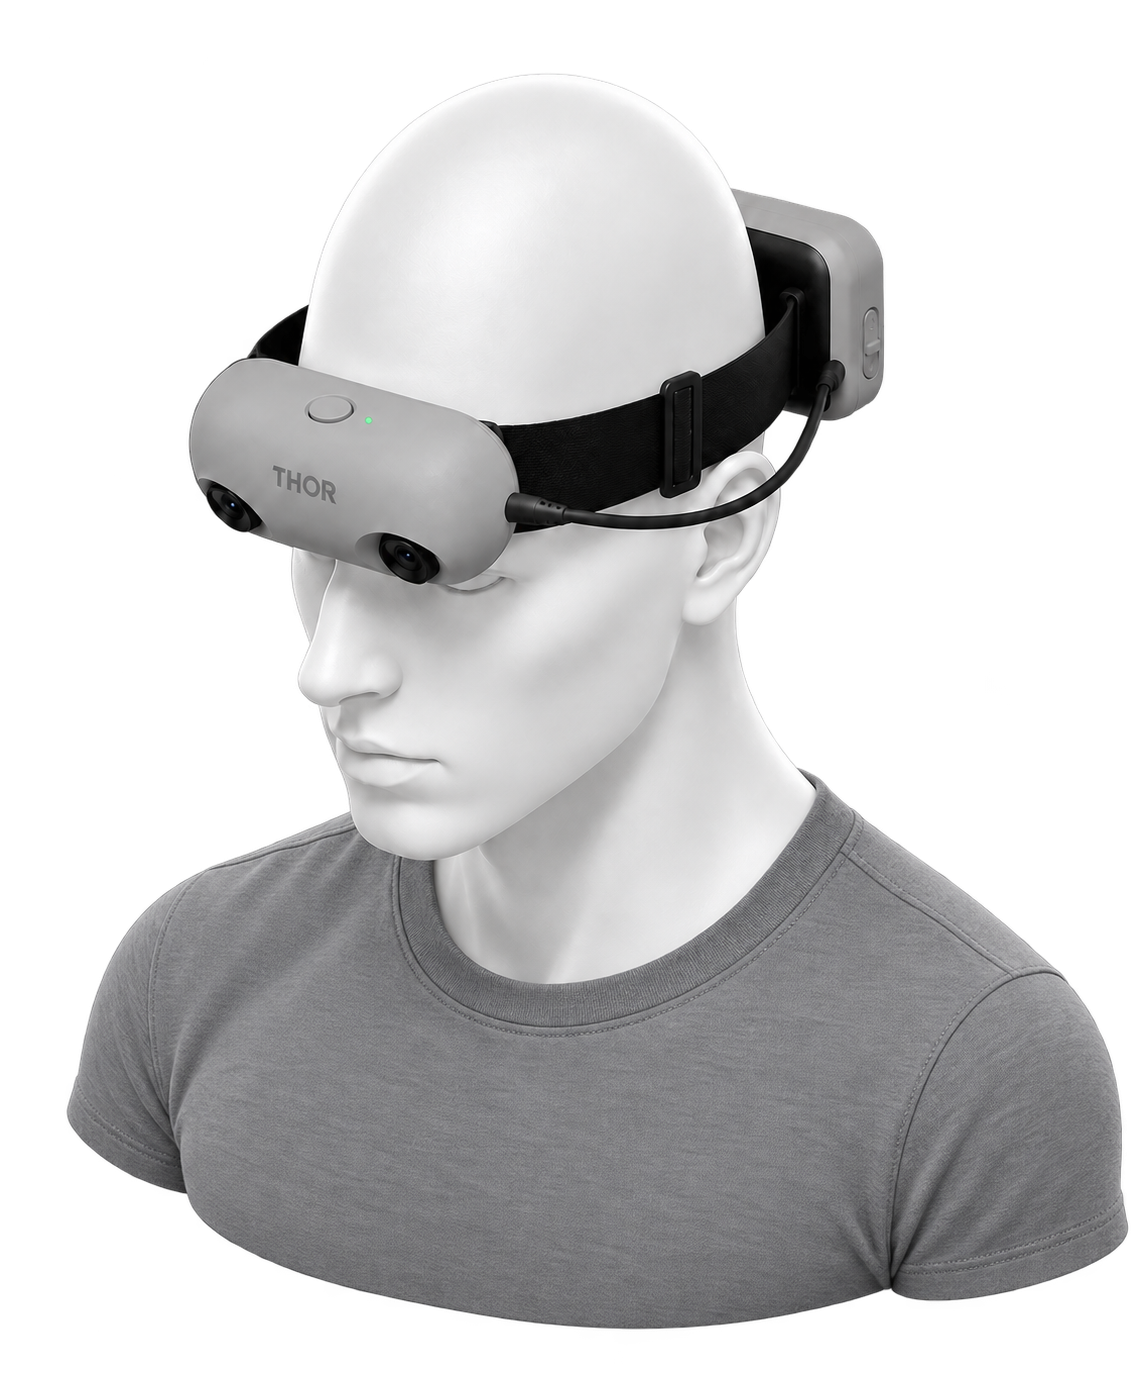
Capture / Specification-based configuration
Dual-camera visual-inertial capture
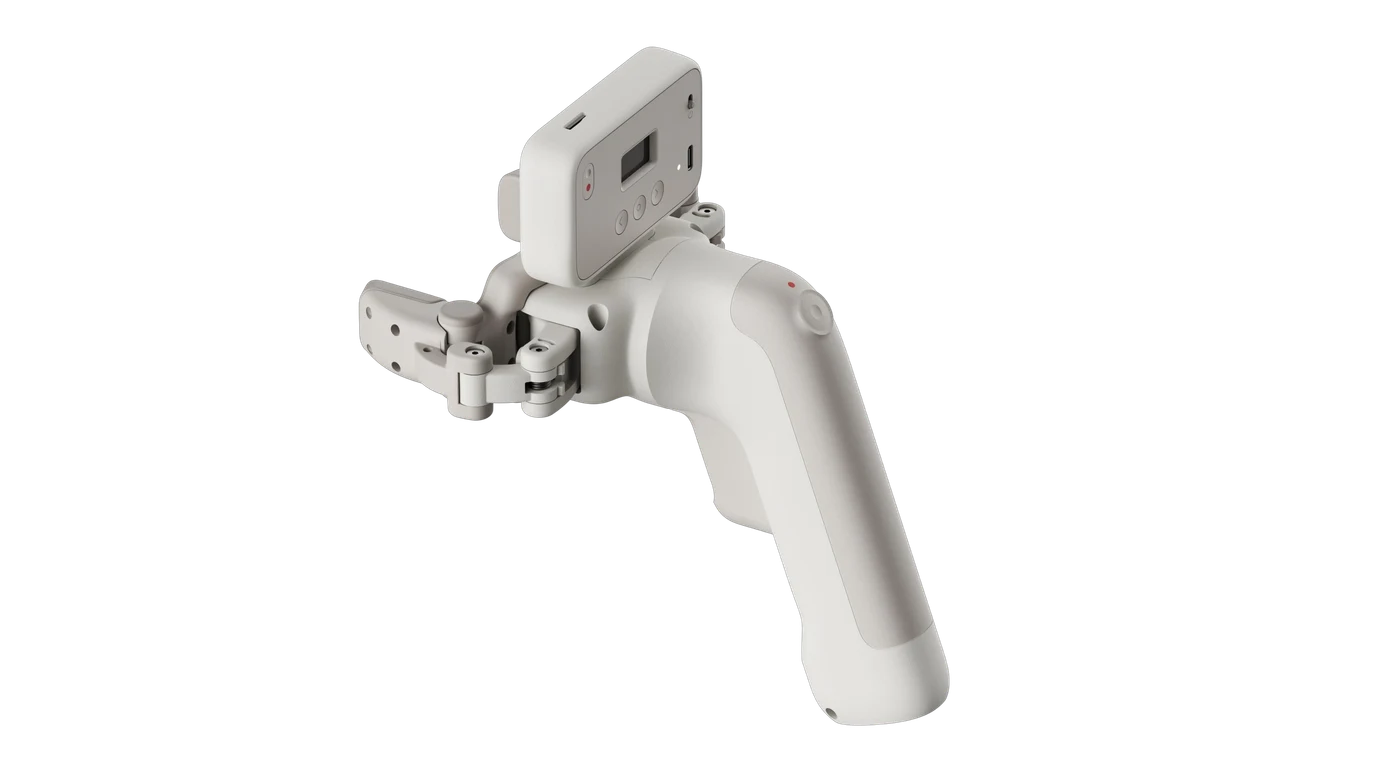
Capture / Specification-based configuration
Handheld manipulation demonstrations
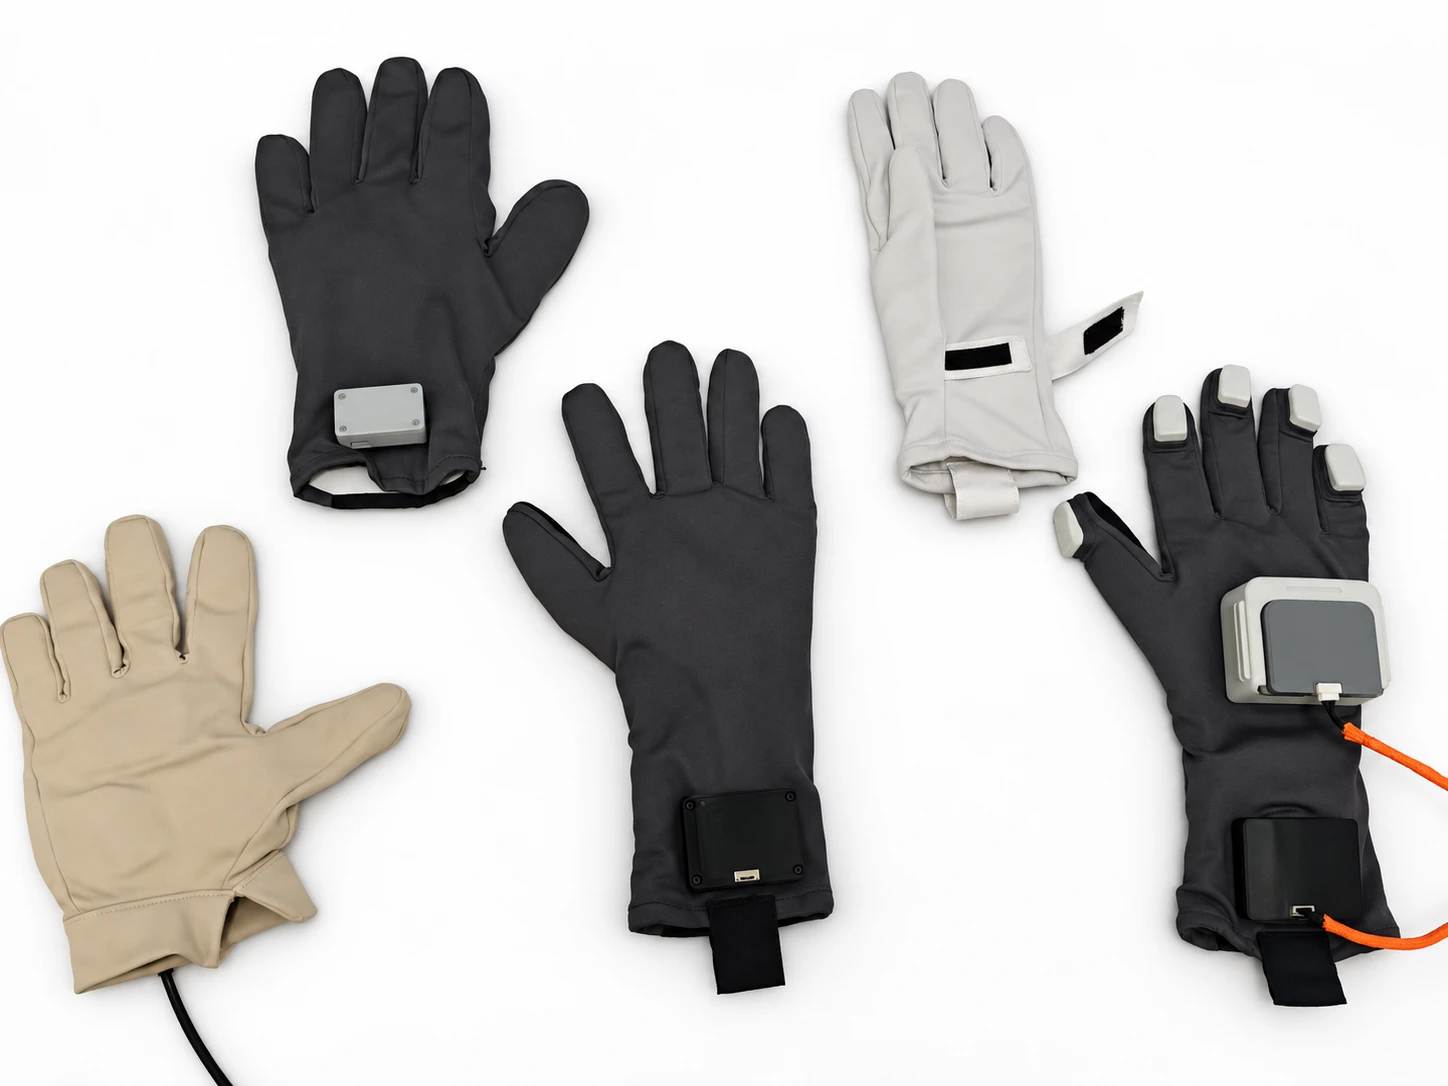
Capture / Specification-based configuration
Contact sensing and electromagnetic tracking
Build with Actrium
Define the devices, data and evaluation your project needs.