Independent operator station
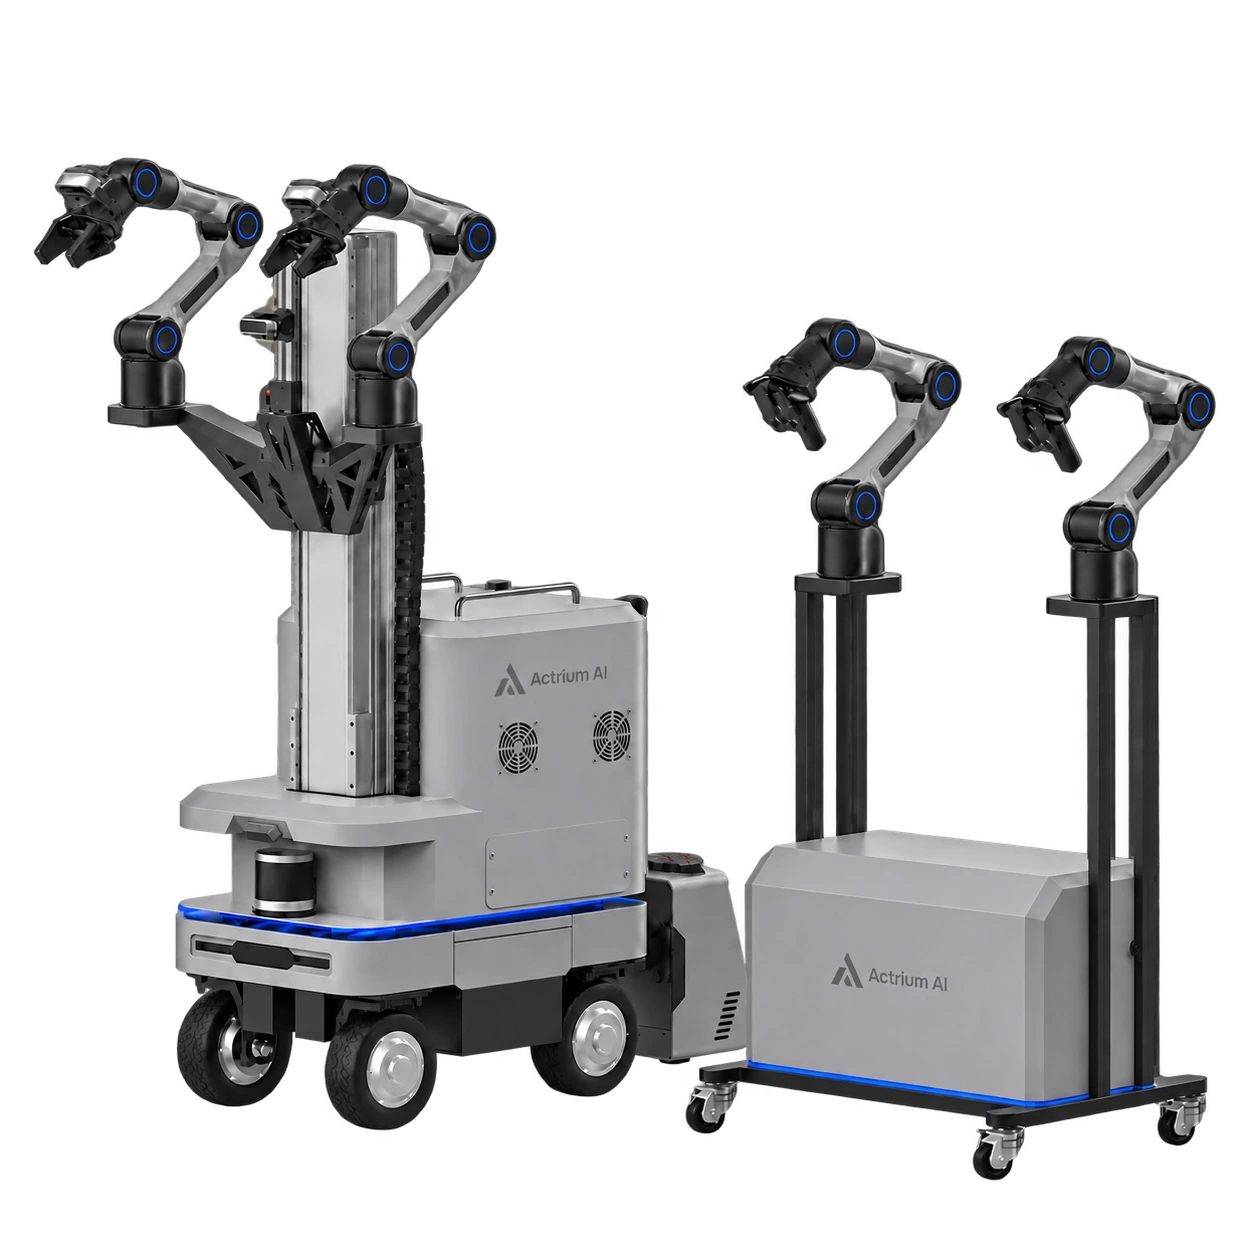
Leader-arm pose mapping controls the follower system with separate space for the operator and robot.

Robotics
Project configuration
System overview
Separate the operator station from the mobile execution system. The dual-arm platform supports experiments across operating heights and workspaces while the teleoperation station remains fixed.
Configuration, lead time and delivery scope confirmed with your inquiry.
Design & capability
Leader-arm pose mapping controls the follower system with separate space for the operator and robot.
The reference system uses four-wheel drive and steering, a lifting arm structure, navigation and ROS lift drivers.
Three depth cameras and one lidar form the reference sensing configuration.
Configuration details and measurement conditions.
| Structure | Four-wheel drive and four-wheel steering |
|---|---|
| Dimensions | 720 x 500 x 345 mm |
| Base payload | 120 kg |
| Maximum speed | 2 m/s |
| Protection | IP54 |
| Temperature | -10 to 40 C |
| Reference runtime | 3 hours fully loaded; 6 hours unloaded |
These are base specifications, not arm payload or complete-system working runtime.
| Height | 1322.4-1891.6 mm |
|---|---|
| Dual-arm width | 757.7 mm |
| Mobile platform width | 774.6 mm |
| Arms | 4 x Atlas A6 |
| Sensing | 3 depth cameras / 1 lidar |
| Compute | RTX 4070 / 4080 / 4090 / 5070 / 5080 / 5090 workstation options. Power, cooling, installation and software compatibility require engineering review; high-power GPUs may use an external workstation. |
| Display / keyboard | 11.6-inch / Logitech |
| Power | Portable power station; redundant battery and auto-charging dock inclusion to be confirmed |
Delivery and validation
Project integration configuration. Images are concept illustrations, not delivery photographs or engineering CAD. Reference specifications do not establish completed integration, proprietary ownership or brand authorization. Final hardware and performance are subject to project validation and acceptance.
Training and deployment
Plan GPU compute, model training and hosted inference, with control kept on the robot.
Training & Compute →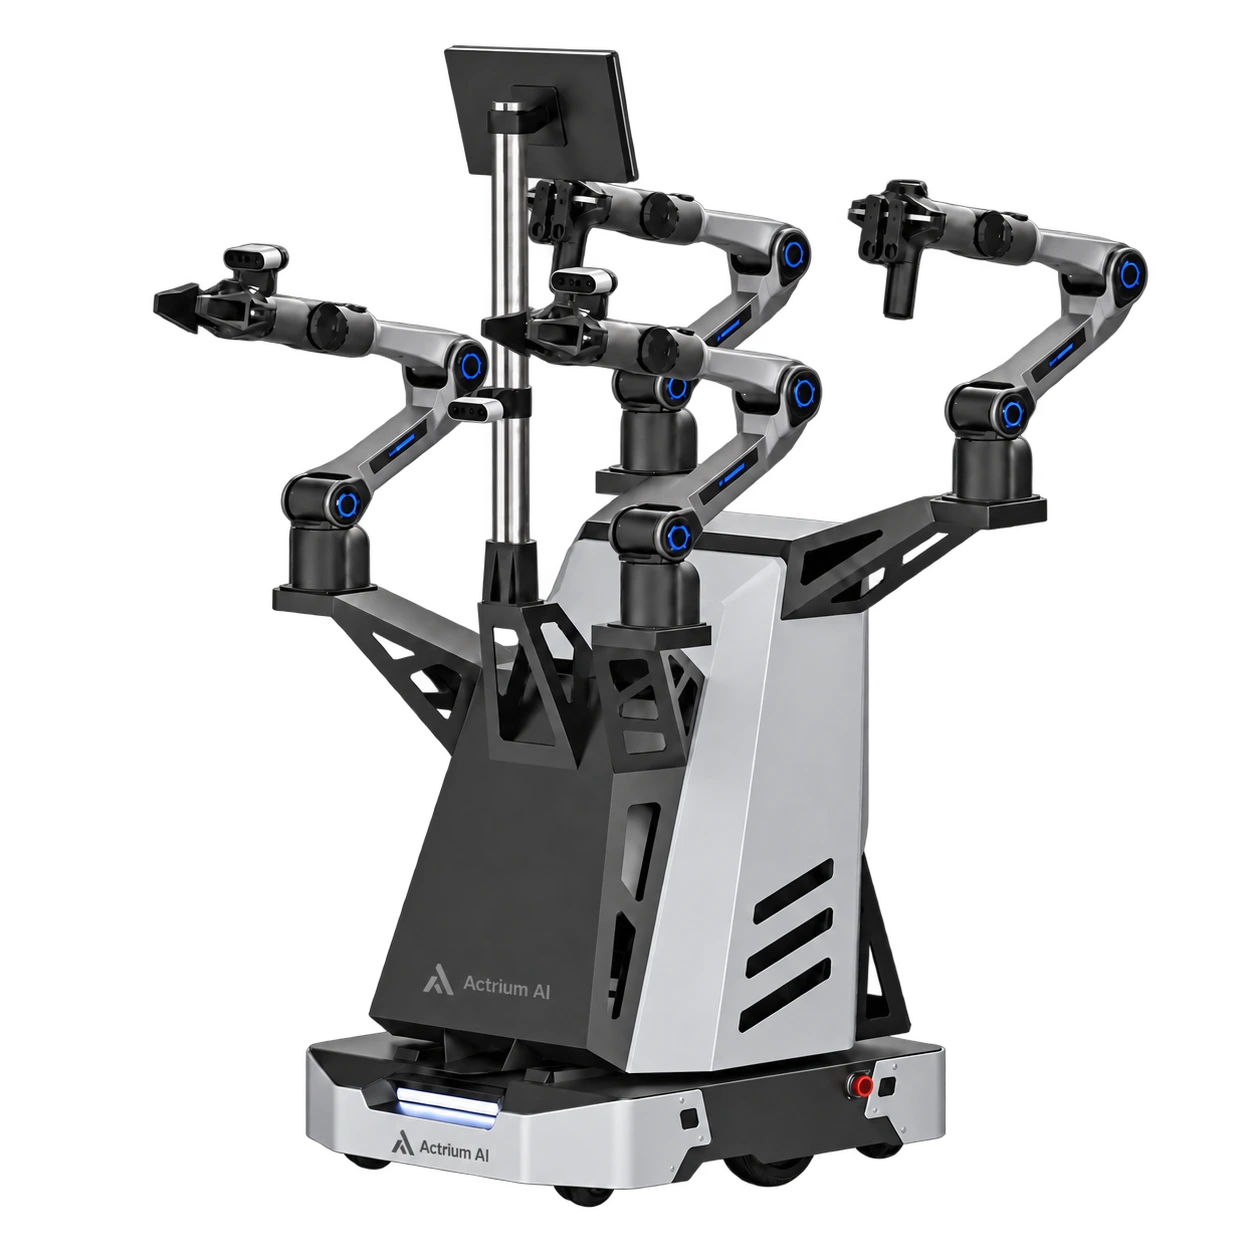
Robotics / Project configuration
Integrated mobile bimanual platform
Robotics / Project configuration
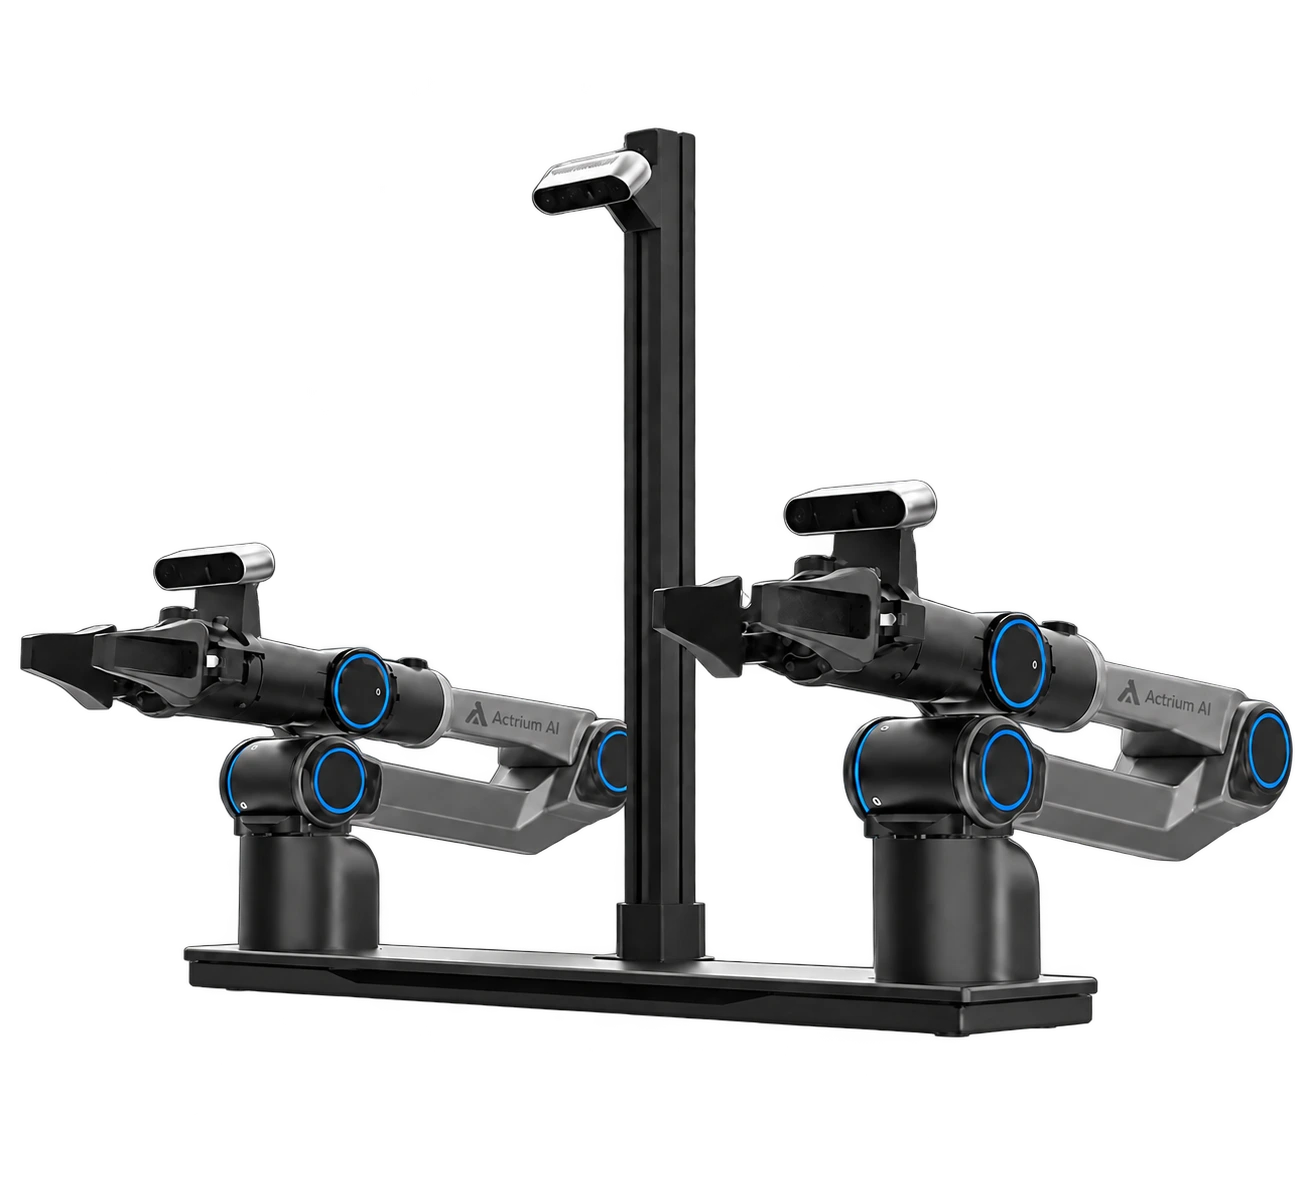
Desktop bimanual learning platform
Capture / Specification-based configuration
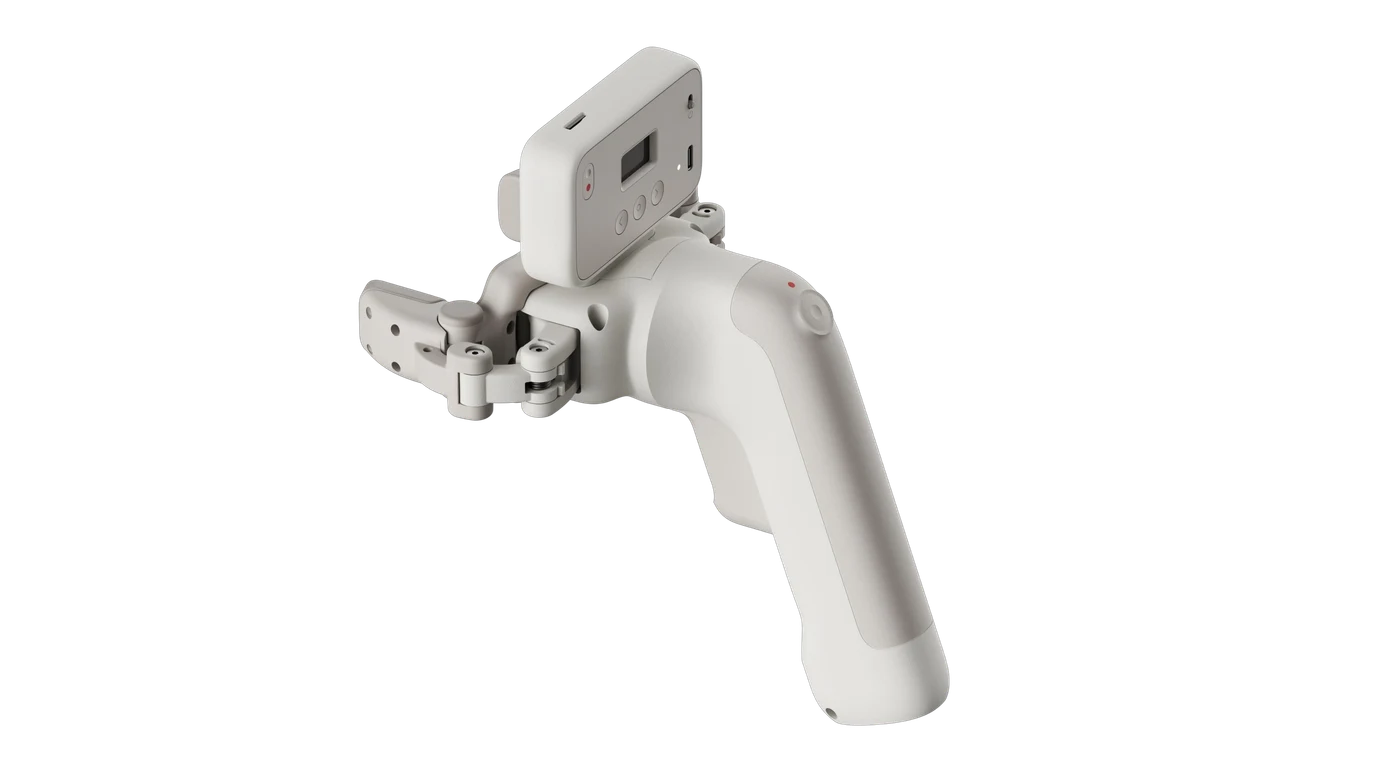
Handheld manipulation demonstrations
Build with Actrium
Define the devices, data and evaluation your project needs.