Core setup
- Select Atlas A6 / A7 / D / M / S for degrees of freedom, workspace and task.
- Specify cameras, end effectors, fixtures and safety equipment.
- Define collection and inference compute, software environment and experiment records.

Solutions
Combine robots, teleoperation, vision and compute for research teams. Connect demonstrations, baseline training and physical evaluation in a reproducible experiment with a defined task and acceptance criteria.
University laboratories, enterprise R&D teams and robotics developers
Robot, camera, end effector, compute and software versions, with interfaces and responsibility boundaries.
Teleoperation procedure, recorded fields, calibration and demonstrations within the agreed scope.
Training configuration, data version, runtime, weights and licenses when included in the project.
Fixed conditions, success rate, task duration, interventions and failure categories with raw logs.
Accept hardware, safety functions, recording, model reproducibility and physical task results separately. Success rates must name the task, objects, starting states and trial count.
Robotics / Project configuration
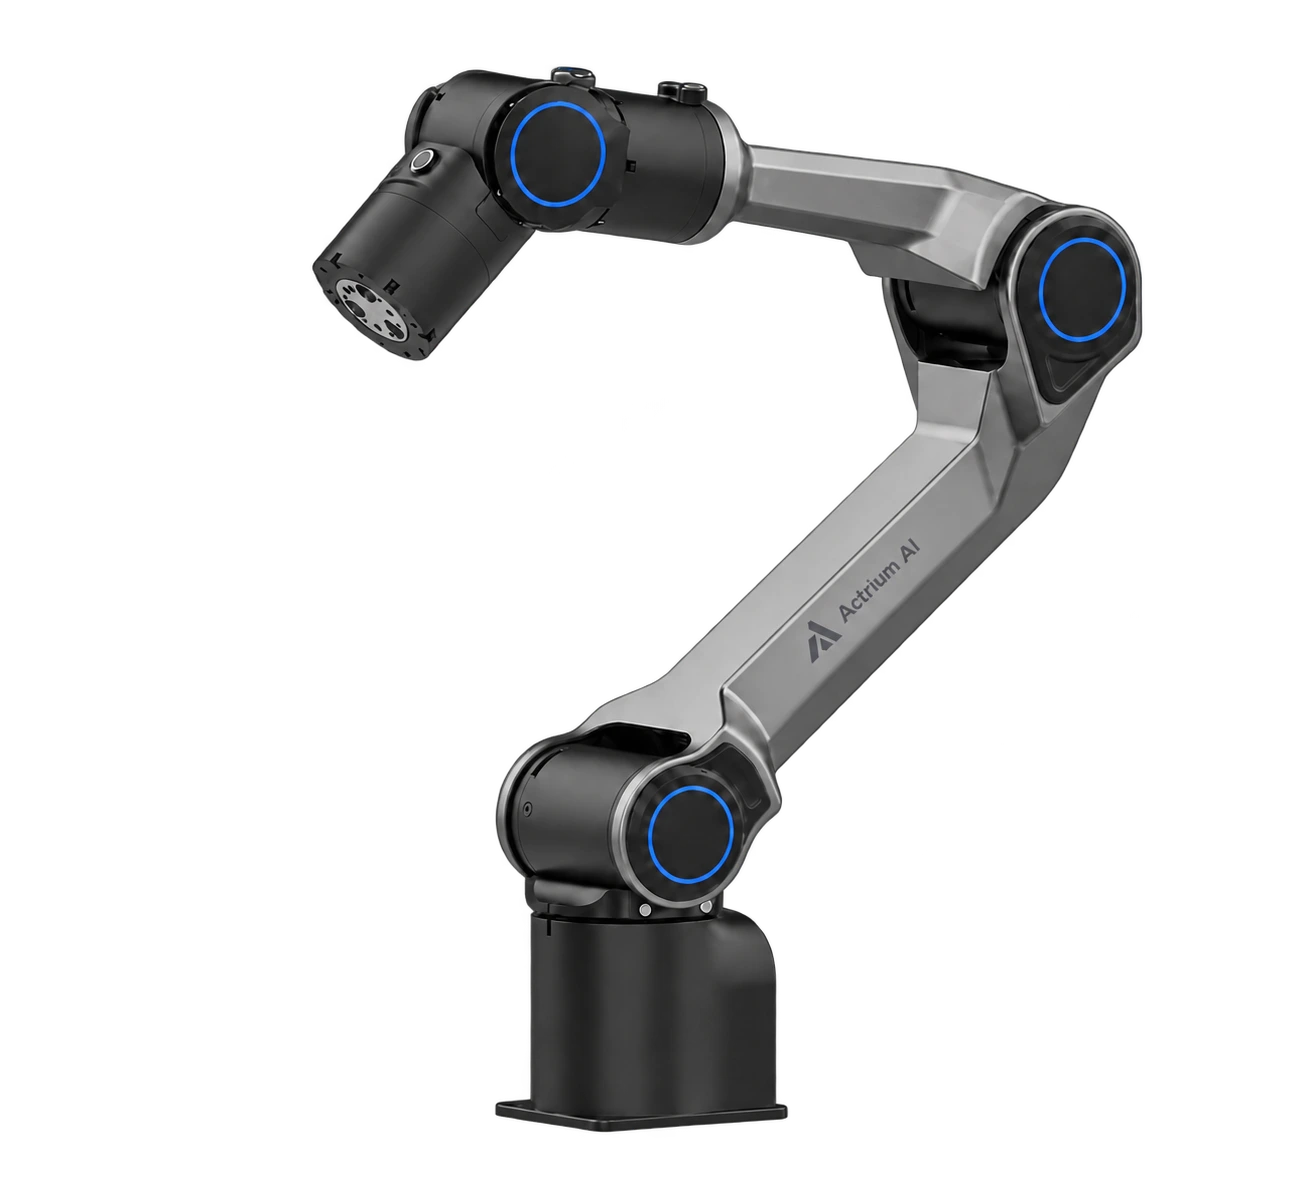
Six-axis research manipulator
Robotics / Project configuration
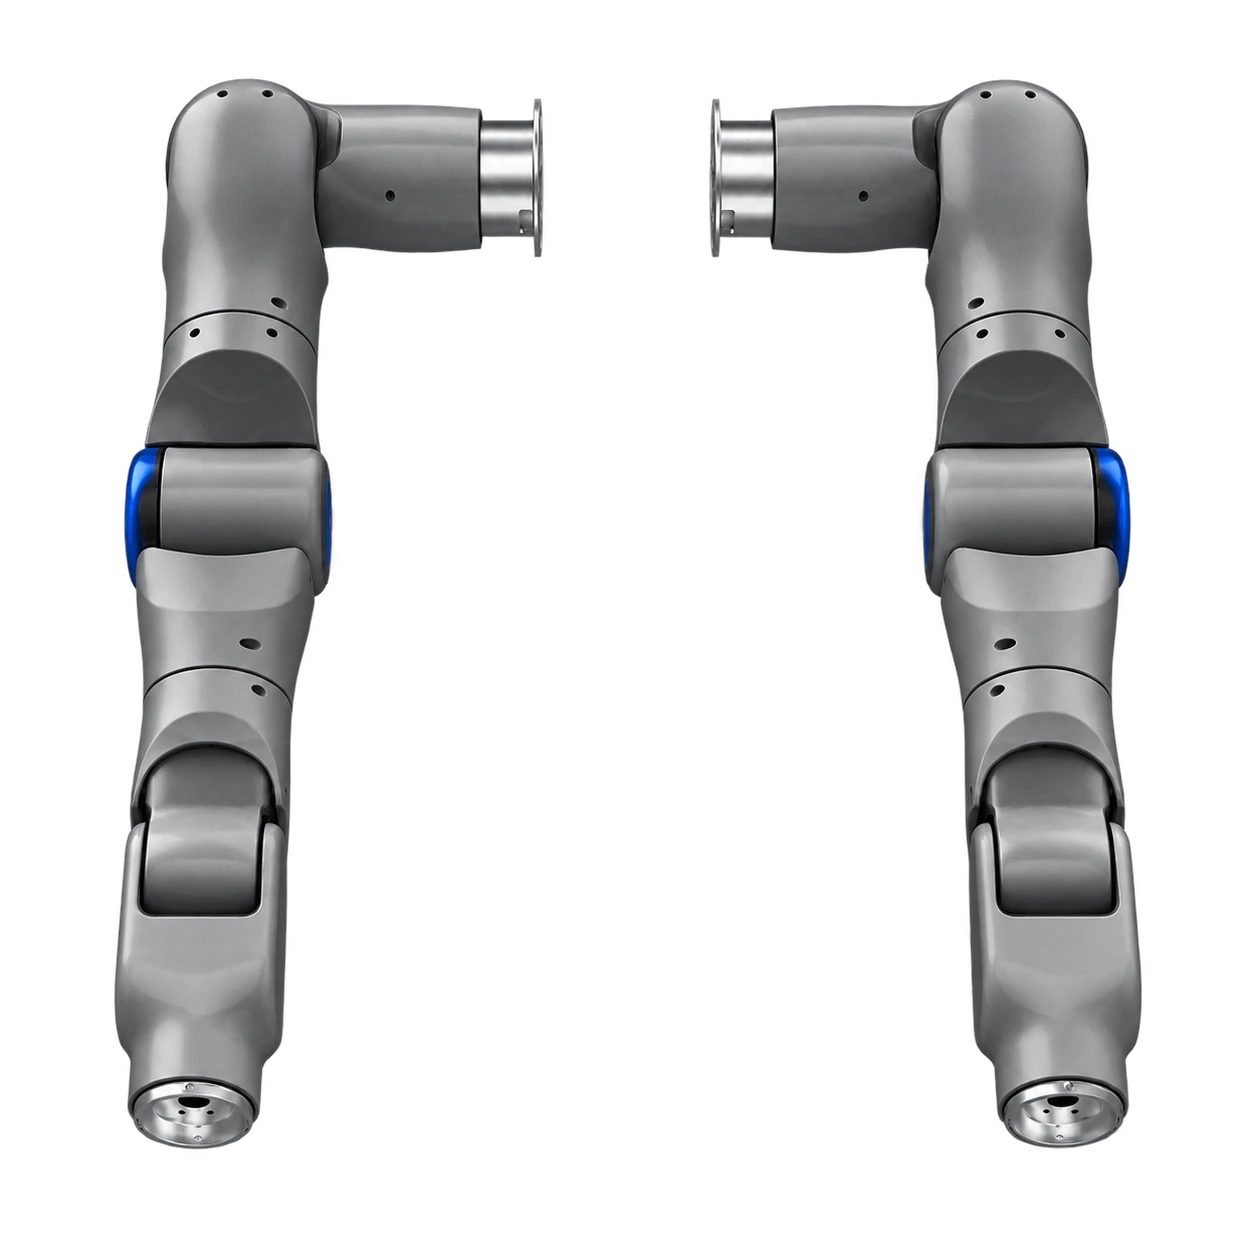
Seven-axis lightweight research manipulator
Robotics / Project configuration
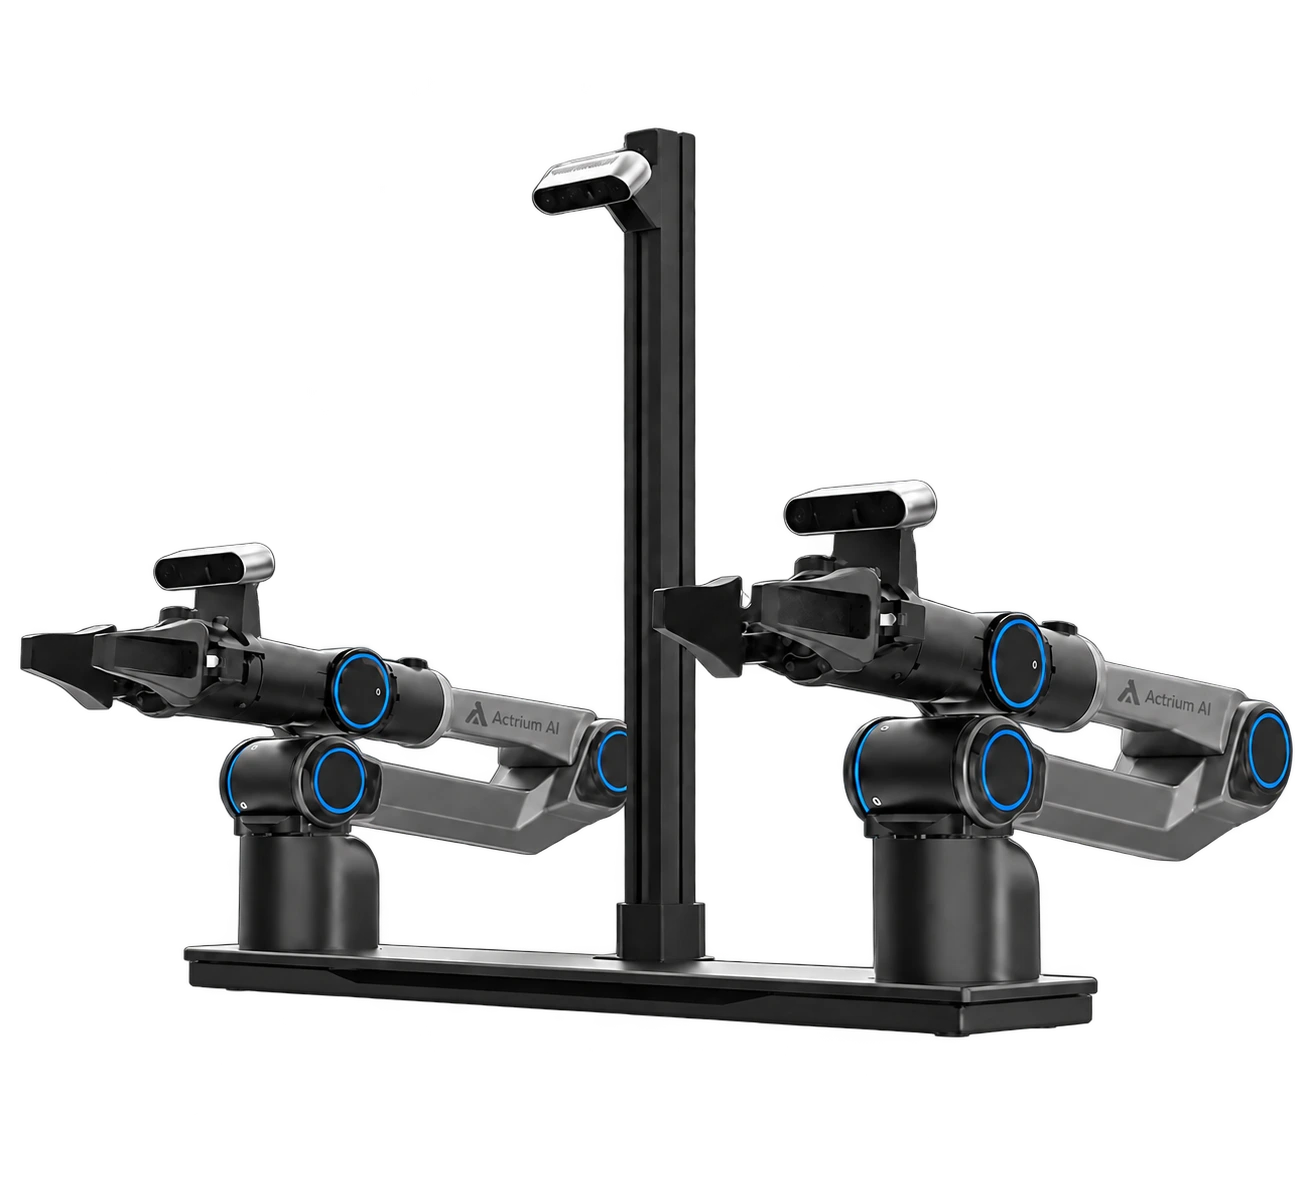
Desktop bimanual learning platform
Robotics / Project configuration
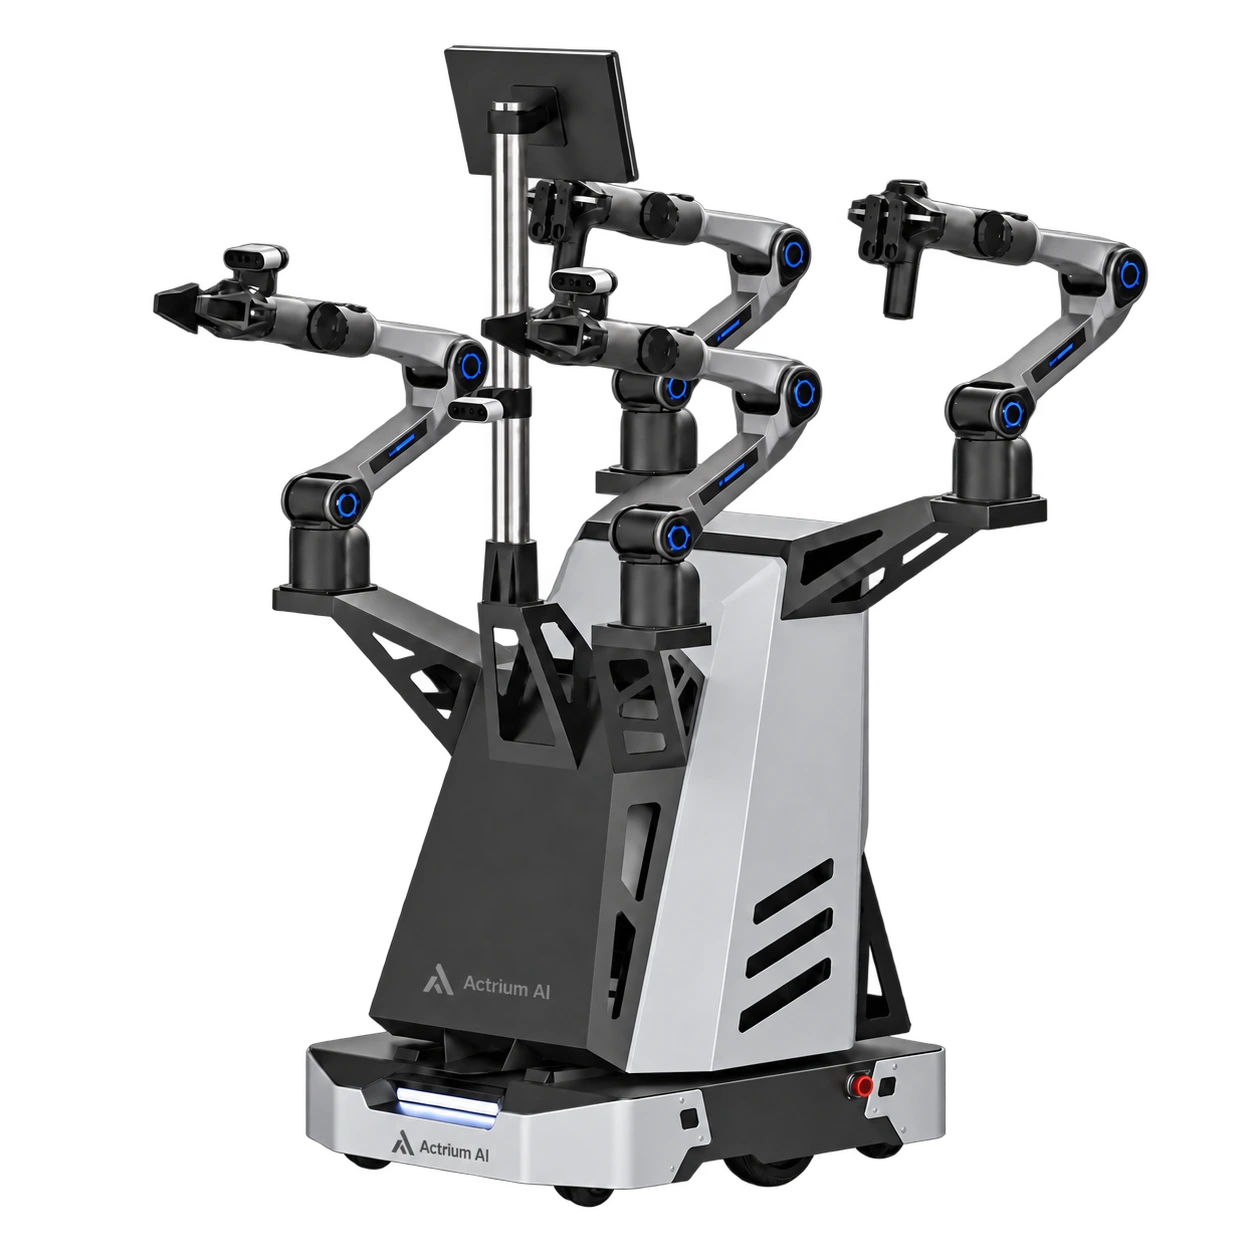
Integrated mobile bimanual platform
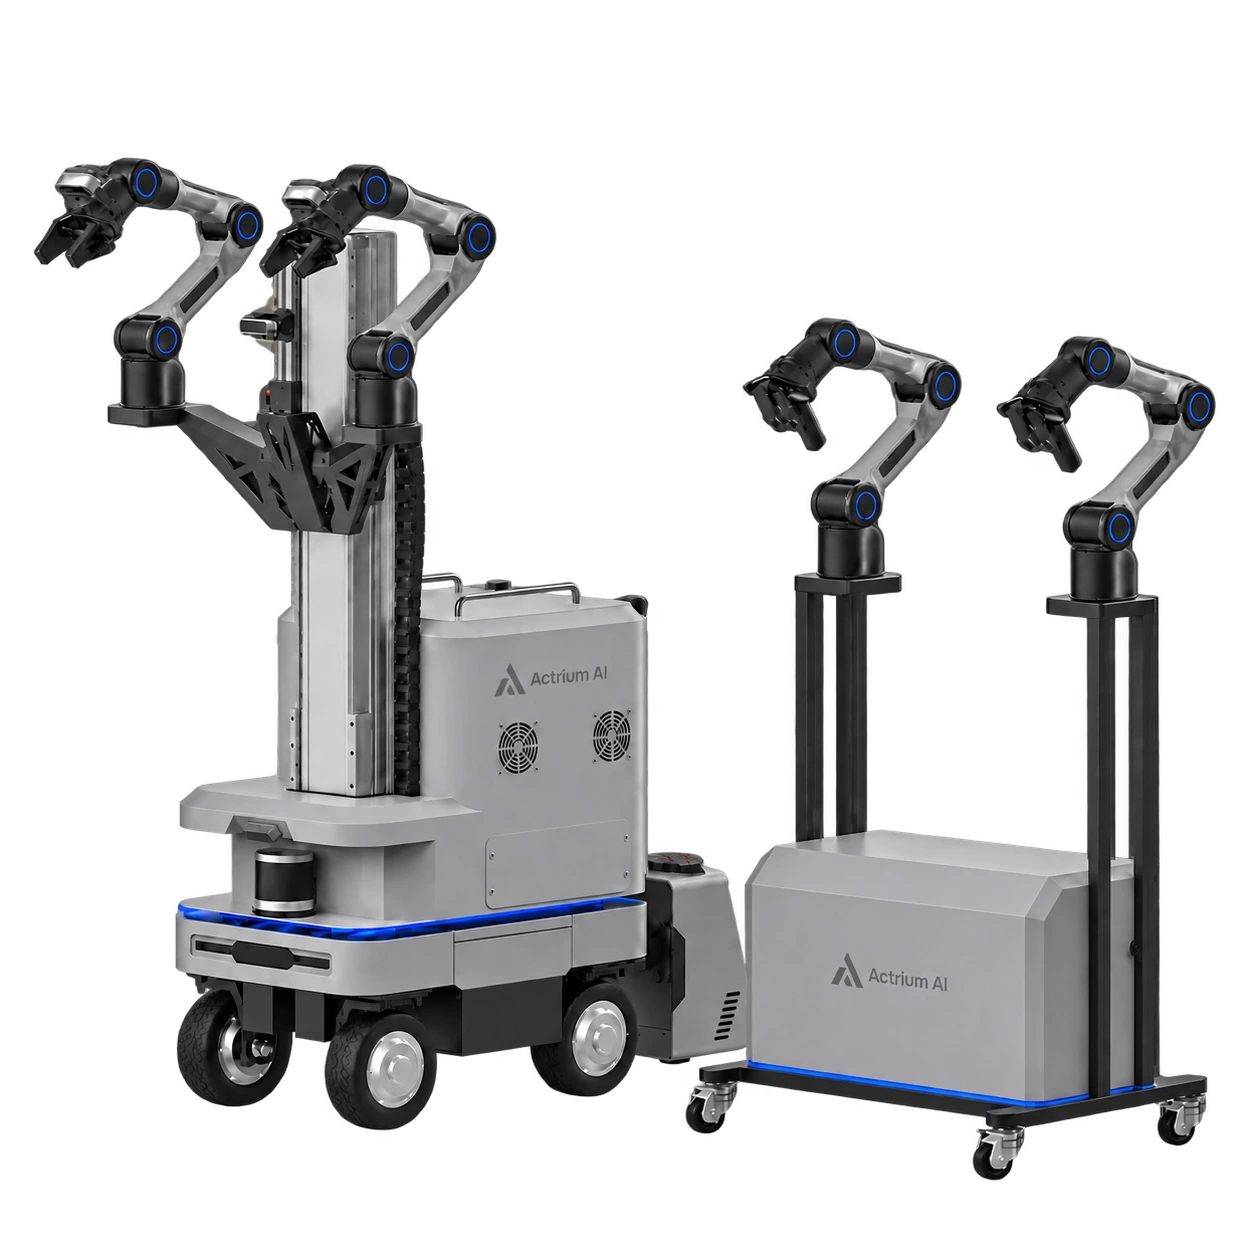
Robotics / Project configuration
Modular mobile bimanual platform
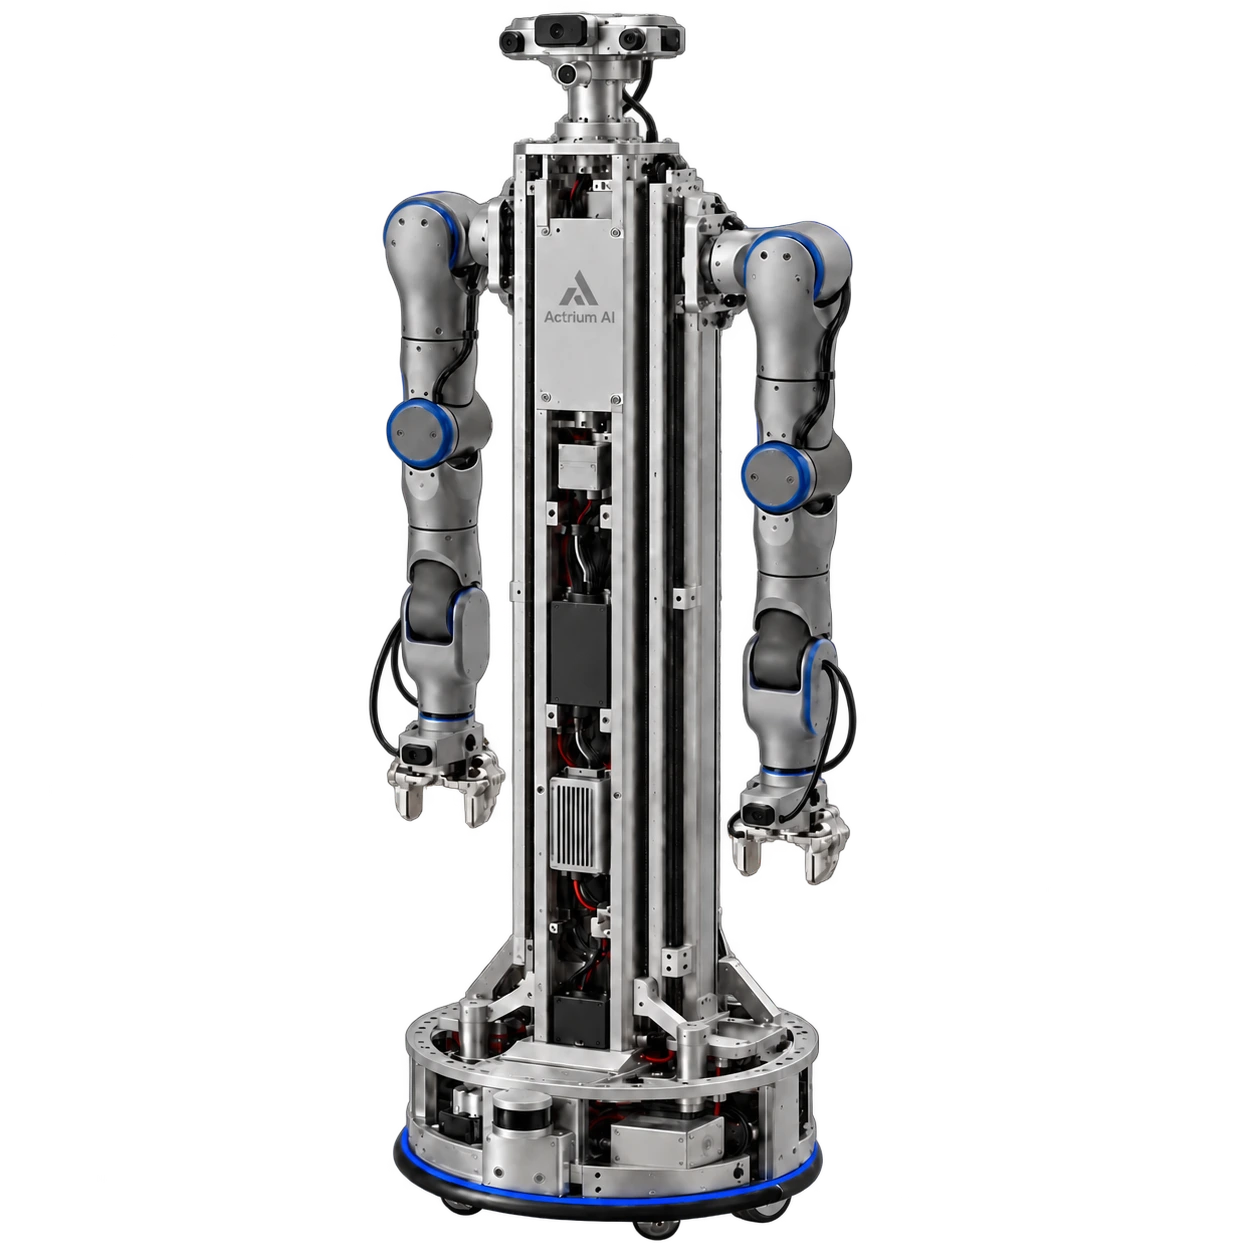
Robotics / Research concept
Open-frame wheeled humanoid research concept
A GPU option does not include training services. Model adaptation, optimization and evaluation need explicit scope. High-power GPUs may require an external workstation.
Plan compute, model integration and evaluation for your workstation.
Training & Compute →Build with Actrium
Define the devices, data and evaluation your project needs.